Reading a Humanoid Robot Spec Sheet: What "20 kg Payload" Really Means
Source: https://sourcebotics.com/guides/reading-a-humanoid-robot-spec-sheet/
TL;DRCompare humanoid payload, motion, runtime, environmental requirements and development access against your task. Prepare a configuration-specific quotation and acceptance brief.
Payload: define the working conditions
A payload figure is useful when its conditions match your application. Ask whether it describes one arm or both, a continuous load or a short-duration maximum, and the reach and posture used. Include the end effector, cables and carried object in the load calculation.
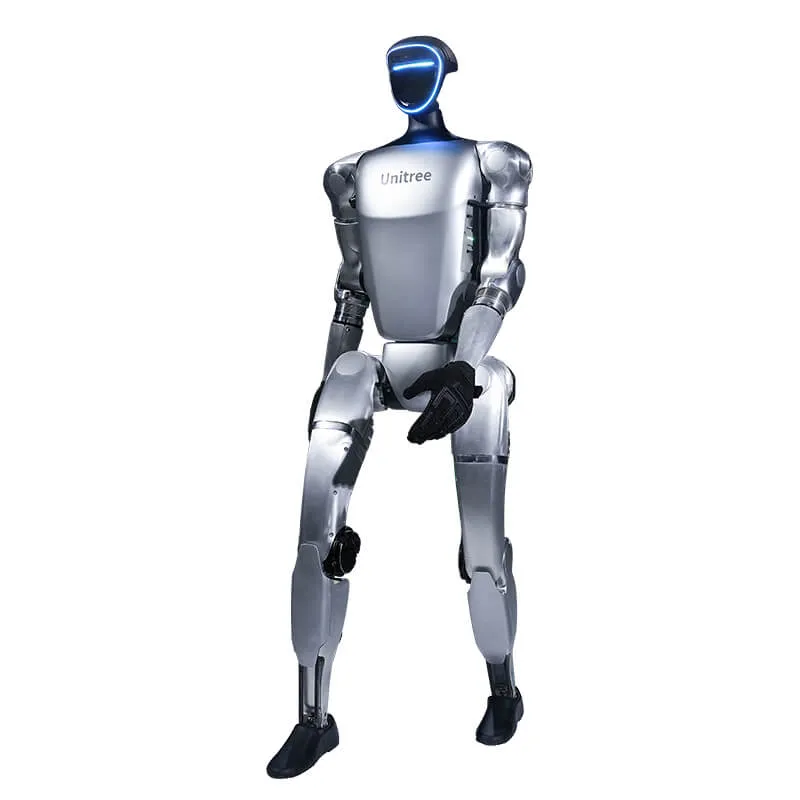
Unitree's G1 specification table distinguishes G1 and G1 EDU and states that maximum arm load varies with arm extension. This is a practical example of why the model and operating conditions belong beside the number.
For your quotation, specify the object mass, working reach, grasp arrangement and whether the robot stands, walks or uses both arms. Request the supplier's supported load conditions and an application-specific acceptance plan.
Motion: locate the controlled axes
Total joints, actuators and independently commanded motions describe different aspects of the mechanism. Request a joint map showing the legs, waist, arms, wrists and hands, together with the commands exposed by the control interface.
Optional wrists or hands can change the configuration. Compare the movements required by your task, including reach and orientation, rather than selecting solely by a total DOF figure. The dexterous hand specification guide explains the distinctions for end effectors.
Walking speed: specify the route and load
Record the surface, gradient, obstacles, payload, firmware and intended run length. Ask which speed the delivered configuration supports under those conditions and how the operating area will be managed.
Use those requirements to compare proposed systems and agree a representative route demonstration. The teleoperation and autonomy guide helps identify operator involvement and recovery requirements.
Runtime: budget the working cycle
Ask for endurance under the planned motion, computing and manipulation workload. Include recharge time, spare batteries, replacement procedure and any power-down requirements in the operating plan.
A removable battery and a battery that can be replaced without interrupting operation are different capabilities. Confirm the procedure for the quoted model. For transport documentation and spare-pack arrangements, use the robot shipping guide.
Dimensions and mass: plan handling and workspace
Request standing and transport dimensions, equipment mass with the supplied battery and accessories, and the crated shipment dimensions. Check these against the workspace, storage area, doorways and handling equipment.
The supplier should identify the recommended lifting points, transport fixtures and installation requirements. Include the equipment needed to move, secure and maintain the robot in the scope of supply.
Control mode: describe the delivered task
A demonstration should identify whether the task uses teleoperation, a programmed sequence, learned control or autonomous operation. Request the operating conditions, required operator inputs, intervention frequency and recovery procedure.
Agree repeated task trials and the evidence to record. This makes the acceptance criteria specific to your application and the delivered hardware and software.
Environmental protection: request the applicable rating
For dust, moisture or washdown exposure, request the model-specific protection rating and its stated scope. Confirm whether it covers the assembled robot, supplied connectors and installed accessories.
If the documentation does not state a rating, obtain the manufacturer's permitted operating conditions before selecting the robot for that environment. Review safeguarding and system safety requirements with the responsible integration team.
Development access: specify the complete software package
The G1 manufacturer table lists secondary development separately for G1 EDU. For a development purchase, specify the exact hardware edition, accessible commands, firmware, host environment and required documentation.
The official Unitree SDK 2 repository provides build instructions and examples. Match the selected SDK revision and example to the delivered robot and firmware, then ask for a reproducible integration workflow. See the G1 configuration guide for the quotation scope.
Put the requirements into the quotation
| Requirement | Details to specify | Evidence to request |
|---|---|---|
| Payload | Arm arrangement, reach, posture, motion and duty | Supported operating conditions and task results |
| Motion | Required axes, wrist and hand configuration | Joint map and command interface |
| Mobility | Surface, route, load and run length | Representative route demonstration |
| Runtime | Working cycle, compute load and charging plan | Endurance conditions and battery procedure |
| Handling | Equipment and crate dimensions, installed mass | Packing and handling instructions |
| Control | Operating mode, operator input and recovery | Continuous trials and intervention records |
| Environment | Dust, moisture and accessory installation | Model-specific ratings and permitted conditions |
| Development | Hardware edition, firmware and API access | SDK revision, documentation and working example |
Use the procurement checklist to record these requirements. Share your shortlist, application, quantity and destination with the Sourcebotics sourcing desk.
FAQ
Does a payload number apply to every reach and motion?
Confirm the manufacturer's stated conditions for the exact model. Specify the arm arrangement, reach, posture and duty cycle needed by your application.
Is total DOF the same as independent joint control?
Request the joint and actuator map and the commands exposed by the interface. Moving joints can be coupled or passive.
How should I assess a robot without a published IP rating?
Request the permitted operating conditions and any model-specific protection documentation. Keep environmental approval open until your requirements are supported.
What belongs in a development-platform quotation?
The hardware edition, firmware, required API access, SDK revision, host environment, accessories and documentation, together with a reproducible integration workflow.
What is the source of the model examples?
The G1 examples use Unitree's manufacturer specification table and official SDK repository, reviewed on 2026-10-14. Final configuration, pricing, availability and acceptance requirements are defined in the quotation.
Planning a robotics purchase? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk