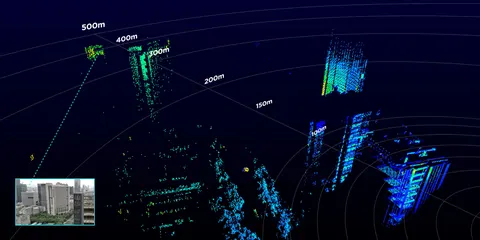
- Range at 100 klx
- 40 m at 10% reflectivity; 70 m at 80%
- Field of view
- 360° horizontal; −7° to +52° vertical
- Point rate
- 200,000 points/s, first return
LiDAR & Perception Sensors from China
Compare LiDAR and perception sensors by ranging distance, field of view, point rate, and host interfaces for mobile robot navigation and 3D mapping.
Choose a manufacturer or product type, then narrow the specifications.
- Range
- 30 m at 90% reflectivity; 15 m at 10%
- Field of view
- 360° × 90° normal; 360° × 96° in negative-angle mode, with shorter range in the extra 6°
- Effective point rate
- 64,000 points/s; distinct from 128,000 raw samples/s
- Range
- 30 m at 10% NIST reflectivity and 100 klux; website maximum 75 m
- Field of view
- 120° × 90°
- Point rate
- 260,000 points/s
- Daylight range, 100 klx
- 190 m at 10%; 230 m at 20%; 320 m at 80% reflectivity
- Field of view
- 70.4° × 77.2° non-repetitive; 70.4° × 4.5° line scan
- Return modes
- 240k / 480k / 720k points/s: single / dual / triple
- Channels
- 96
- Range
- 60 m maximum; 30 m at 10% reflectivity
- Field of view
- 360° × 90°
- Channels
- 16
- Range
- 150 m maximum; datasheet does not specify target reflectivity
- Field of view
- 360° × 30° (−15° to +15°)
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quoteCompare 7 matching models
| Model | Type | Points/s | FOV | Quote | ||
|---|---|---|---|---|---|---|
| Livox Mid-360 | Non-repetitive scanning | 40 m at 10% / 70 m at 80% reflectivity, 100 klx | 200,000 points/s (first return) | 360° horizontal; −7° to +52° vertical | On request | Quote |
| Unitree L2 | Rotating mirror | 30 m at 90% reflectivity; 15 m at 10% | 64,000 effective points/s | 360° × 90° normal; 360° × 96° negative-angle mode | <$1k | Quote |
| RoboSense E1R | Solid-state | 30 m at 10% NIST reflectivity and 100 klux; 75 m maximum | 260,000 points/s | 120° × 90° | On request | Quote |
| Hesai JT16 | Mini mechanical 360-degree lidar | 30 m | Request specification | 360 x 40 deg | On request | Quote |
| Livox Avia | Non-repetitive / repetitive scanning | 190 m at 10% / 230 m at 20% / 320 m at 80% reflectivity, 100 klx; 450 m at 80%, 0 klx | 240,000 single / 480,000 dual / 720,000 triple return points/s | 70.4° × 77.2° non-repetitive; 70.4° × 4.5° line scan | On request | Quote |
| RoboSense Airy (96-channel configuration) | Spinning | 60 m maximum; 30 m at 10% reflectivity | 856,320 points/s | 360° × 90° | On request | Quote |
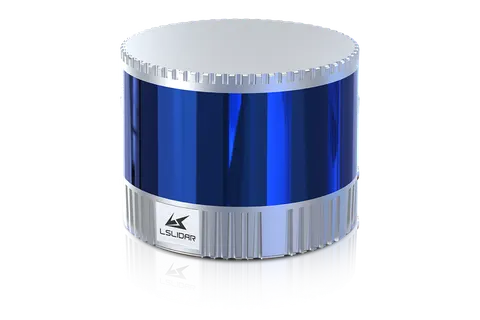
| Leishen C16 (16-channel) | Mechanical spinning | 150 m maximum in earlier datasheet; target reflectivity not specified | 320,000 single-return / 640,000 dual-return points/s | 360° × 30° (−15° to +15°), earlier datasheet | On request | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
LiDAR & Perception FAQ
How is LiDAR detection range specified on manufacturer datasheets?
Compare range at the same target reflectivity, ambient light and return mode. Maximum range and low-reflectivity detection range are different figures; use the exact model datasheet and test conditions.
What should I verify for mobile robot LiDAR integration?
Check minimum detection distance (blind zone), field of view, time-synchronization support (PTP/PPS), IMU integration, power draw, and ROS 2 driver compatibility.