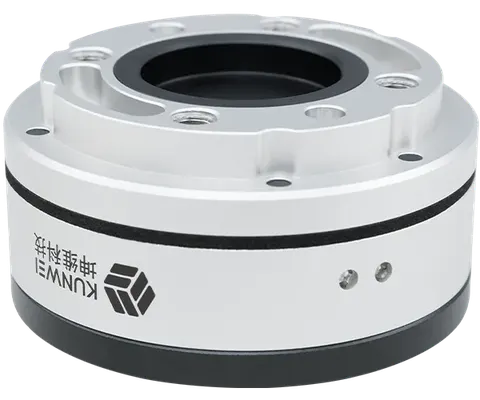
Daimon Robotics DM-Tac G

Two-finger gripper with integrated vision-based tactile feedback and programmable force–position control. The 1 kg assembly offers a 95 mm stroke and 120 Hz tactile acquisition; standard control uses RS-485 Modbus RTU and digital I/O.

Price on requestRequest a configuration-specific quotation covering the product, required accessories, support, freight and taxes.
Dimensions184.6 × 162.3 × 67 mm
Weight1 kg
Stroke95 mm

Technical specifications

Product documentation
GRIPPER
Dimensions184.6 × 162.3 × 67 mmReference ↗
Weight1 kgReference ↗
Stroke95 mmReference ↗
Unilateral clamping force45–60 NReference ↗
Position repeatability±0.03 mmReference ↗
Opening / closing time0.9 s / 0.9 sReference ↗
SENSING & CONTROL
Tactile sampling rate120 HzReference ↗
Supply24 V DC; confirm allowable tolerance for supplied revisionReference ↗
Standard controlModbus RTU over RS-485; digital I/OReference ↗
Optional conversionTCP/IP, USB 2.0, CAN 2.0A, PROFINET or EtherCAT through the specified configurationReference ↗

Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.

Supplier

Daimon Robotics 戴盟机器人
Shenzhen · est. 2023 · 10–50 employees

Daimon Robotics specializes in vision-based tactile sensing (DM-Tac class) and supplies high-resolution fingertip tactile sensors for manipulation research and dexterous-hand integration.

View profile

Product documentation

Manufacturer and distributor references for model selection and technical review. Latest reference check: September 7, 2026.

Configuration & quotation

Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.

Price bandPrice on request

Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.

Discuss this configuration

FAQ

Which configuration should be quoted?

Provide object dimensions, grasp force and required tactile outputs for the gripper configuration.

What should be agreed before ordering?

Specify standard RS-485 or the required protocol converter, plus the tactile-processing host and software package.

Related models

Considering Daimon Robotics DM-Tac G? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.

Request a quote

— The Sourcebotics sourcing desk

Chat