Horizon Robotics Journey 6P
- Chip/SoC
- Journey 6P (J6P)
- AI Compute (TOPS)
- 560 TOPS
- CPU
- Arm Cortex-A78AE cluster
Price on request
Compare robot motion controllers and edge AI compute modules by processor architecture, TOPS performance, fieldbus I/O, and real-time operating system.
As of October 2026, this catalog lists 27 models from 10 manufacturers. Filter by the requirements below, then request a quotation for the exact configuration.
Choose a manufacturer or product type, then narrow the specifications.
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quote| Model | Processor / SoC | CPU | AI compute (TOPS) | Memory | Operating system | Quote |
|---|---|---|---|---|---|---|
| Horizon Robotics Journey 6P | Journey 6P (J6P) | Arm Cortex-A78AE cluster | 560 TOPS | Request specification | Linux / QNX / Android | Quote |
| Horizon Robotics Journey 6M | Journey 6M (J6M) | Arm Cortex-A78AE cluster | 128 TOPS | Request specification | Linux / QNX | Quote |
| Horizon Robotics Journey 6E | Journey 6E (J6E) | Arm Cortex-A CPU cluster | 80 TOPS | Request specification | Linux / QNX | Quote |
| Horizon Robotics Journey 5 | Journey 5 (J5) | 8x Arm Cortex-A55 | 128 TOPS | Request specification | Linux / QNX | Quote |
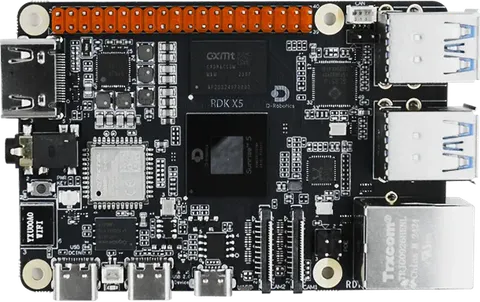
| D-Robotics RDK X5 | Sunrise 5 | 8x Arm Cortex-A55 @1.5 GHz | 10 TOPS BPU | 4 GB / 8 GB LPDDR4 | Ubuntu 22.04 + TogetheROS / ROS 2 | Quote |
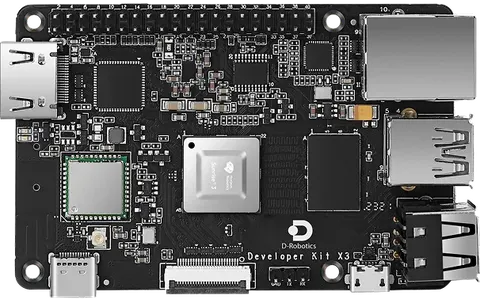
| D-Robotics RDK X3 | Sunrise 3 | 4x Arm Cortex-A53 @1.5 GHz | 5 TOPS BPU | 2 GB / 4 GB LPDDR4 | Ubuntu + TogetheROS / ROS 2 | Quote |
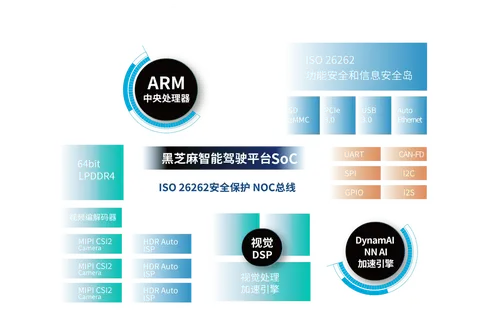
| Black Sesame C1200 | Wudang C1200 | Arm Cortex-A / Cortex-R multi-core cluster | Request specification | Request specification | Linux / QNX / AUTOSAR | Quote |
| Black Sesame A1000 | Huashan A1000 | Arm Cortex-A55 cluster | 58 TOPS INT8 | Request specification | Linux / QNX | Quote |
| Rockchip RK3588 | RK3588 | 4x Cortex-A76 + 4x Cortex-A55 | Up to 6 TOPS at INT8 (three-core NPU; theoretical capability) | LPDDR4/LPDDR4X/LPDDR5 controller; up to 32 GB address space in Datasheet V1.6, not populated RAM | Android/Linux ecosystem support; board-specific BSP and delivered OS image must be specified | Quote |
| Rockchip RK3576 | RK3576 | 4x Cortex-A72 + 4x Cortex-A53 | 6 TOPS INT8 | LPDDR4/4X/5 | Android / Linux | Quote |
| Rockchip RK3568 | RK3568 | 4x Cortex-A55 @2.0 GHz | 1 TOPS INT8 | LPDDR3/4/4X, up to 8 GB | Android / Linux / Ubuntu | Quote |
| Rockchip RK3588S | RK3588S | 4x Cortex-A76 + 4x Cortex-A55 | 6 TOPS INT8 | LPDDR4/4X/5 | Android / Linux | Quote |
| Allwinner T527 | T527 | 8x Arm Cortex-A55 | 2 TOPS NPU | LPDDR4/4X | Android 13 / Tina Linux | Quote |
| Allwinner A733 | A733 | 4x Cortex-A76 + 4x Cortex-A55 | 3 TOPS NPU | up to 16 GB LPDDR4X/LPDDR5 | Android 15 / Linux | Quote |
| Axera AX650N | AX650N | 8x Arm Cortex-A55 | 18 TOPS INT8 / 72 TOPS INT4 | LPDDR4X | Linux | Quote |
| Axera AX630C | AX630C | 2x Arm Cortex-A53 | 3.2 TOPS INT8 / 12.8 TOPS INT4 | Integrated LPDDR4 | Linux | Quote |
| SOPHGO BM1684X | BM1684X | 8x Arm Cortex-A53 @2.3 GHz | 32 TOPS INT8; 16 TFLOPS FP16/BF16 | LPDDR4X (12 GB on module SKUs) | Linux with SOPHON SDK / TPU-MLIR | Quote |
| SOPHGO BM1684 | BM1684 | 8x Arm Cortex-A53 | 17.6 TOPS INT8; 2.2 TFLOPS FP32 | Request specification | Linux with SOPHON SDK | Quote |
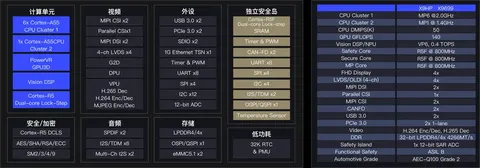
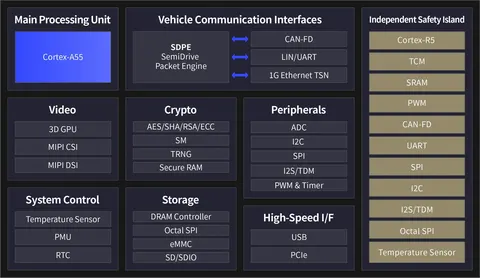
| SemiDrive X9HP | X9HP | 8x Arm Cortex-A55 + Cortex-R5 safety island | Request specification | Request specification | Linux / QNX / Android with hypervisor | Quote |
| SemiDrive E3 | E3 series MCU | Multi-core Arm Cortex-R5F in lockstep | Request specification | Request specification | AUTOSAR Classic / FreeRTOS | Quote |
| SemiDrive G9 | G9 series | Arm Cortex-A + Cortex-R multi-core | Request specification | Request specification | Linux / AUTOSAR | Quote |
| Googol Tech GTS-800-PV | DSP + FPGA motion engine | Request specification | Request specification | Request specification | Windows / Linux with C/C++ API | Quote |
| Googol Tech GUC-T | Embedded RISC + FPGA motion engine | Request specification | Request specification | Request specification | Embedded RTOS with OtoStudio programming | Quote |
| ZMotion ZMC432 | Embedded ARM + FPGA motion engine | Request specification | Request specification | Request specification | Embedded RTOS with ZDevelop / ZBasic / C++ API | Quote |
| ZMotion ZMC432N | Embedded ARM + FPGA motion engine | Request specification | Request specification | Request specification | Embedded RTOS with ZDevelop | Quote |
| ZMotion VPLC532E | Multi-core ARM with vision co-processing | Request specification | Request specification | Request specification | Embedded Linux with ZDevelop and vision library | Quote |
| D-Robotics RDK S100 | Request specification | 6 × Arm Cortex-A78AE at 1.5 GHz | 80 TOPS BPU (INT8 equivalent) | 12 GB LPDDR5 | Request specification | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
Specify motion-loop deadlines separately from perception and policy-inference latency. Compare controller scheduling, bus timing, CPU/GPU load, fault handling and recovery under the complete robot workload.
Verify isolated CAN FD / CAN ports, EtherCAT RJ45 or M12 ports, GMSL2/MIPI camera inputs, hardware trigger/PPS sync pins, wide-range DC input voltage, and thermal dissipation.
Availability of English documentation, JetPack or Ubuntu LTS images, and open kernel drivers varies by hardware platform. Include your target OS, middleware (ROS 2 Humble/Jazzy), and SDK requirements in your inquiry.