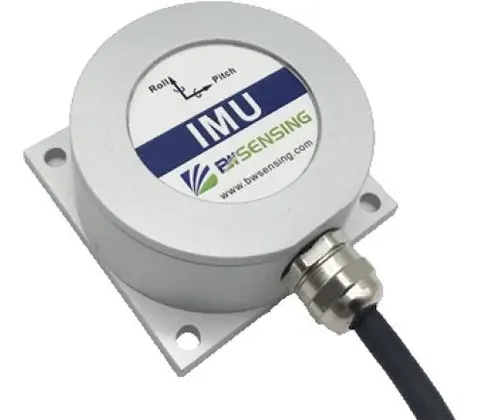
- Type
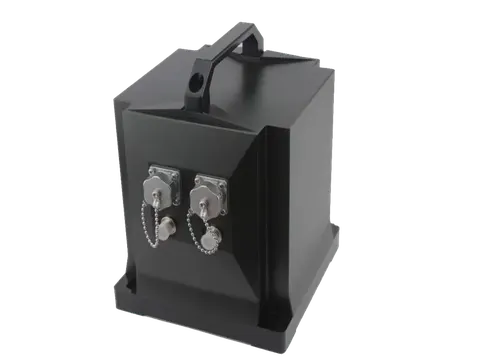
- MEMS IMU (6-axis)
- Gyro Bias Stability
- <=4.5 deg/h (10 s smoothing); <=2 deg/h (Allan variance)
- Angular Random Walk
- <=0.18 deg/sqrt(h)
IMU & Positioning Modules from China
Browse inertial sensors, AHRS and GNSS positioning modules. Select the measurement your robot needs, then compare output rate, bias stability, synchronization and host connection.
As of July 2026, this catalog lists 18 models from 5 manufacturers. Filter by the requirements below, then request a quotation for the exact configuration.
Choose a manufacturer or product type, then narrow the specifications.
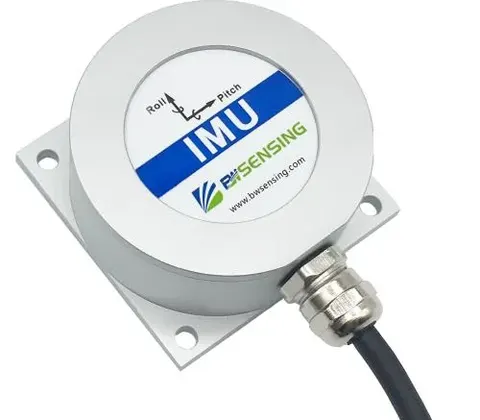
- Type
- MEMS IMU (6-axis)
- Gyro Bias Stability
- <2 deg/h (100 s, 1 sigma); <20 deg/h (10 s, 1 sigma)
- Accel Bias
- 0.001 mg (25 C, 100 s, 1 sigma)
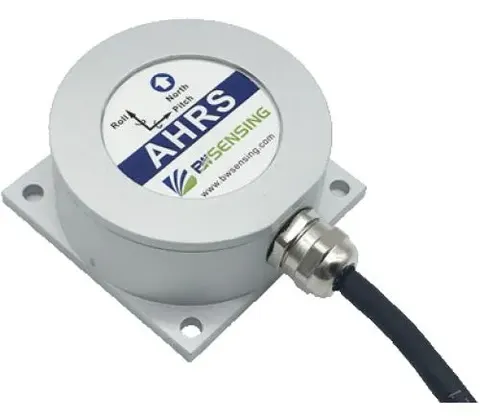
- Type
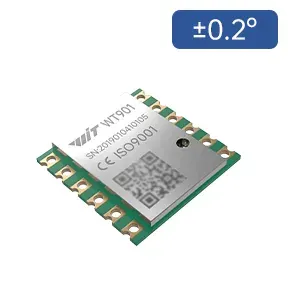
- MEMS AHRS IMU (9-axis)
- Gyro Range
- +/-2000 deg/s (16-bit)
- Accel Range
- +/-16 g (16-bit, 0.01 g accuracy)
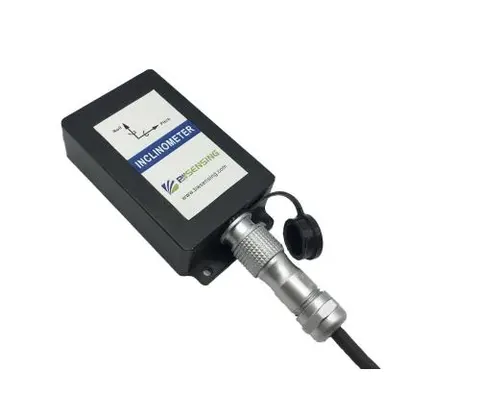
- Type
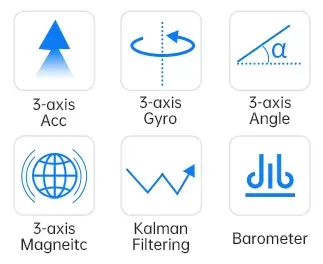
- MEMS AHRS IMU (10-axis)
- Magnetometer
- PNI RM3100
- Sensors
- Accelerometer, gyroscope, magnetometer, barometer
- Type
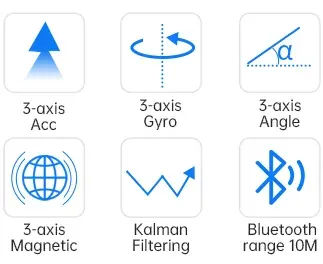
- MEMS AHRS IMU (9-axis, Bluetooth)
- Interface
- Bluetooth + USB
- Certification
- FCC
- Type
- Multi-constellation high-precision GNSS OEM module
- Positioning
- RTK centimetre-level
- Type
- Multi-constellation high-precision GNSS OEM module
- Positioning
- RTK centimetre-level
- Type
- Multi-constellation high-precision GNSS OEM module
- Positioning
- RTK centimetre-level
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quoteCompare 18 matching models
| Model | Sensor type | Gyro bias stability | Gyroscope range | Positioning | Interface | Quote |
|---|---|---|---|---|---|---|
| Asensing IMU5305 | MEMS IMU (6-axis) | <=4.5 deg/h (10 s smoothing); <=2 deg/h (Allan variance) | Request specification | Request specification | UART | Quote |
| BWSENSING IMU200 | MEMS IMU (6-axis) | <2 deg/h (100 s, 1 sigma); <20 deg/h (10 s, 1 sigma) | +/-400 deg/s | Request specification | Request specification | Quote |
| BWSENSING IMU500C | MEMS inertial unit | Request specification | Request specification | Request specification | RS-485 | Quote |
| BWSENSING AH200 | MEMS inertial unit | Request specification | Request specification | Request specification | RS-485 | Quote |
| BWSENSING BW-VG500 | MEMS inertial unit | Request specification | Request specification | Request specification | RS-485 | Quote |
| BWSENSING BW-IMU1200 | Fibre optic gyro IMU (3-axis) | Request specification | Request specification | Request specification | RS-485 | Quote |
| WitMotion WT901 | MEMS AHRS IMU (9-axis) | Request specification | +/-2000 deg/s (16-bit) | Request specification | Request specification | Quote |
| WitMotion HWT901B | MEMS AHRS IMU (10-axis) | Request specification | Request specification | Request specification | Request specification | Quote |
| WitMotion BWT901CL | MEMS AHRS IMU (9-axis, Bluetooth) | Request specification | Request specification | Request specification | USB | Quote |
| SinoGNSS K9 | Multi-constellation high-precision GNSS OEM module | Request specification | Request specification | RTK centimetre-level | Request specification | Quote |
| SinoGNSS K8 | Multi-constellation high-precision GNSS OEM module | Request specification | Request specification | RTK centimetre-level | Request specification | Quote |
| SinoGNSS K7 | Multi-constellation high-precision GNSS OEM module | Request specification | Request specification | RTK centimetre-level | Request specification | Quote |
| Senodia SH3001 | MEMS IMU (6-axis) | Request specification | Request specification | Request specification | Request specification | Quote |
| Senodia SH3201 | MEMS IMU (6-axis) | Request specification | Request specification | Request specification | Request specification | Quote |
| Senodia SH5001 | MEMS IMU (6-axis) | Request specification | Request specification | Request specification | Request specification | Quote |
| Senodia SH5201T | MEMS IMU (6-axis) | Request specification | Request specification | Request specification | Request specification | Quote |
| Senodia SZ007A | MEMS single-axis gyroscope | Request specification | Request specification | Request specification | Request specification | Quote |
| Senodia IMU 445 | MEMS IMU module | Request specification | Request specification | Request specification | Request specification | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
IMU & Positioning FAQ
What is the difference between a 6-axis/9-axis IMU, an AHRS, and an RTK-INS module?
An IMU reports angular rate and acceleration; an AHRS estimates orientation; an integrated GNSS/INS combines satellite and inertial measurements. Confirm which outputs, correction services, antenna arrangement and operating conditions the quoted module supports.
Why does gyro in-run bias stability matter for legged and mobile robots?
Compare gyro bias stability alongside noise, temperature drift, vibration sensitivity and the manufacturer's test method. Evaluate the resulting navigation performance under your robot's motion and sensor-fusion conditions.
What interface and synchronization features should I confirm in an IMU RFQ?
Specify output rate, latency, timestamping, synchronization input, communication bus and ROS 2 driver requirements. Confirm these against the exact module and firmware.