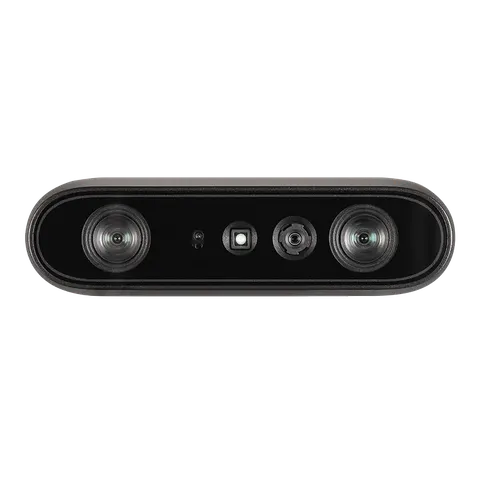
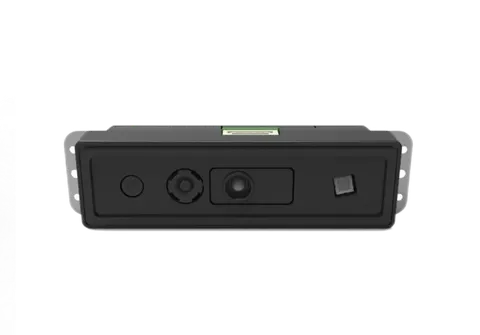
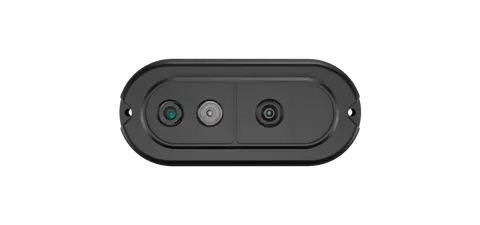
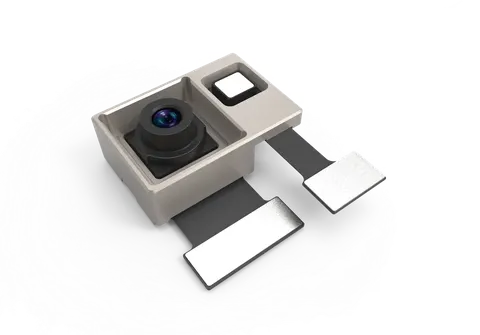
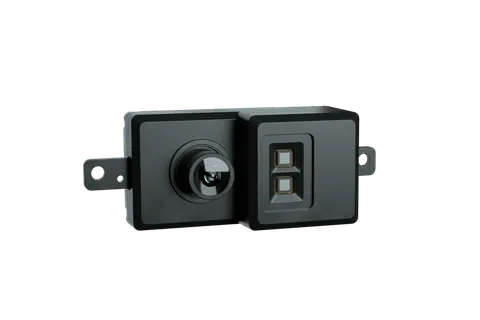
| Orbbec Gemini 335 | Active and passive stereo IR | 0.10-20 m+ (optimal 0.26-3 m) | <1.5% @2 m | up to 1280 x 800 (depth); 1920 x 1080 (RGB) | USB | Quote |
| Orbbec Gemini 335L | Active and passive stereo IR | Request specification | Request specification | Request specification | USB | Quote |
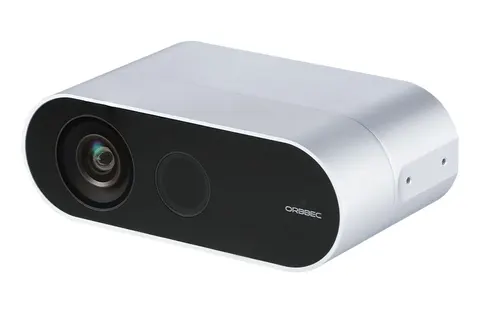
| Orbbec Gemini 2 | Active stereo IR | 0.15-10 m | <=2% @2 m | up to 1280 x 800 (depth); 1920 x 1080 (RGB) | USB | Quote |
| Orbbec Femto Bolt | Time of Flight (850 nm) | 0.25-5.46 m (mode dependent) | <11 mm + 0.1% of distance; random error <=17 mm | 1024 x 1024 @15 fps (WFOV); 640 x 576 @30 fps (NFOV); RGB up to 3840 x 2160 @30 fps | USB | Quote |
| Orbbec Femto Mega | Time of Flight (850 nm) | 0.25-5.46 m (mode dependent) | <11 mm + 0.1% of distance; precision <=17 mm | 1024 x 1024 @15 fps (WFOV); 640 x 576 @30 fps (NFOV); RGB 3840 x 2160 @25 fps | USB / Ethernet | Quote |
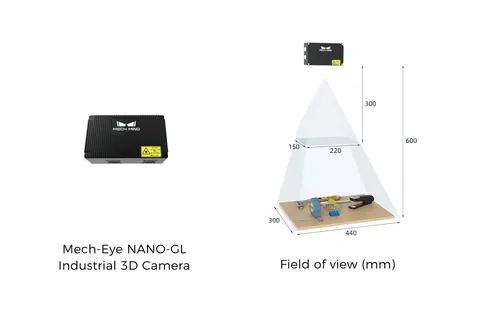
| Mech-Mind NANO | Structured light (LED) | 300-600 mm | 0.1 mm @0.5 m | 1280 x 1024 px | Ethernet | Quote |
| Mech-Mind LOG S | Structured light (LED) | 500-1000 mm | 0.2 mm @1 m | 1280 x 1024 px | Ethernet | Quote |
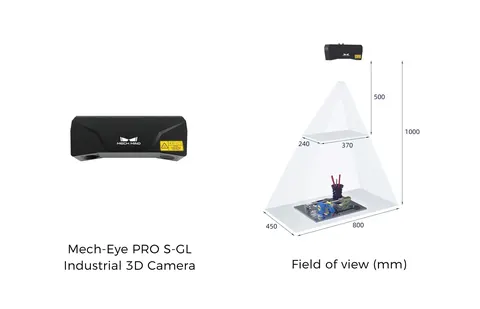
| Mech-Mind PRO S | Structured light (LED) | 500-1000 mm | 0.1 mm @1 m | 1920 x 1200 px | Ethernet | Quote |
| Mech-Mind LOG M | Structured light (LED) | 800-2000 mm | 0.3 mm @2 m | 1280 x 1024 px | Ethernet | Quote |
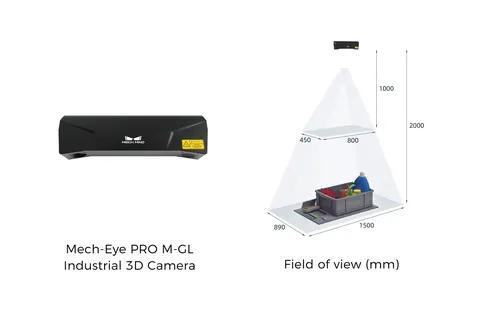
| Mech-Mind PRO M | Structured light (LED) | 1000-2000 mm | 0.2 mm @2 m | 1920 x 1200 px | Ethernet | Quote |
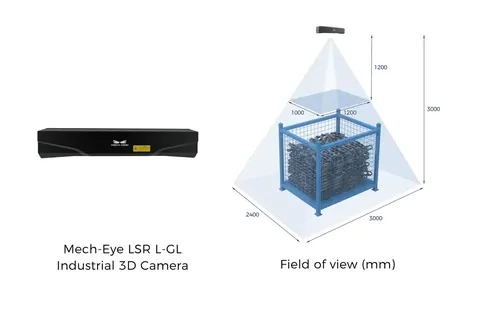
| Mech-Mind LSR L | Structured laser light (Class 2) | 1200-3000 mm | 1 mm @3 m | Depth 2048 x 1536 px; RGB 4000 x 3000 px | Ethernet | Quote |
| Percipio FM851-E2 | Dot-pattern structured light | Request specification | Request specification | Request specification | Ethernet | Quote |
| Percipio FS820-E1 | Binocular speckle structured light | Request specification | Request specification | Request specification | Ethernet | Quote |
| Percipio FM855-E1 | Dot-pattern structured light | Request specification | Request specification | Request specification | Ethernet | Quote |
| Deptrum Aurora 930 | Structured light (nano-photonic projector) | Request specification | Request specification | Request specification | Request specification | Quote |
| Deptrum Nebula 400 | Scanning ToF (sToF) | Request specification | Request specification | Request specification | Request specification | Quote |
| Deptrum Stellar 400 | Indirect ToF (iToF) | Request specification | Request specification | Request specification | Request specification | Quote |
| Deptrum Stellar 800 | Indirect ToF (iToF) | Request specification | Request specification | Request specification | Request specification | Quote |
| Revopoint MetroX Pro | Structured light 3D scanning | Request specification | Request specification | Request specification | Request specification | Quote |
| Revopoint MetroY Ultra | Structured light 3D scanning | Request specification | Request specification | Request specification | Request specification | Quote |
| Revopoint POP 4 | Structured light 3D scanning | Request specification | Request specification | Request specification | Request specification | Quote |
| Revopoint MIRACO Plus | Structured light 3D scanning | Request specification | Request specification | Request specification | Request specification | Quote |
| Revopoint Trackit SR | Blue-laser 3D scanning with optical tracking | Request specification | Request specification | Request specification | Request specification | Quote |
| Orbbec Gemini 336 | Stereo with IR-Pass filter | 0.26–3 m optimal | Request specification | Up to 1280 × 800 depth at 30 fps | USB | Quote |
| Orbbec Gemini 336L | Stereo with IR-pass depth filter | 0.25–6 m ideal; scene and configuration dependent | ±1% at 2 m / ±2% at 4 m; >80% reflective plane, 1280 × 800, central 90% × 90% / 80% × 80% ROI | Depth 1280 × 800 at up to 30 fps; RGB 1280 × 800 at up to 60 fps | USB | Quote |
| Orbbec Gemini 335Le | Stereo with Visible+NIR-pass depth filter | 0.25–6 m ideal; scene and configuration dependent | ±1% at 2 m / ±2% at 4 m; >80% reflective plane, 1280 × 800, central 90% × 90% / 80% × 80% ROI | Depth 1280 × 800 at up to 30 fps; RGB 1280 × 800 at up to 60 fps | Ethernet / RS-485 | Quote |