2D navigation
Compare a scan plane around the base. Check docking distance, target materials and coverage at the proposed mounting height.
Browse 2D scannersCompare 2D and 3D LiDAR for mapping, navigation and obstacle detection. Start with coverage and mounting position, then compare range at the stated target reflectivity, host connection and power.
As of October 2026, this catalog lists 44 models from 11 manufacturers, 14 of them with specifications matched line by line to the cited manufacturer documents. Filter by the requirements below, then request a quotation for the exact configuration.
Choose a manufacturer or product type, then narrow the specifications.
Automotive Ethernet needs a compatible host or media converter.
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quote| Model | Scanning type | Range / conditions | Channels | Field of view | Points/s | Interface | Host connection | Quote | |
|---|---|---|---|---|---|---|---|---|---|
| Livox Mid-360 | Non-repetitive scanning | 40 m at 10% / 70 m at 80% reflectivity, 100 klx | Request specification | 360° horizontal; −7° to +52° vertical | 200,000 points/s (first return) | Ethernet | Ethernet — port to confirm | On request | Quote |
| Unitree L2 | Rotating mirror | 30 m at 90% reflectivity; 15 m at 10% | Request specification | 360° × 90° normal; 360° × 96° negative-angle mode | 64,000 effective points/s | Ethernet / UART | Ethernet — port to confirm | <$1k | Quote |
| RoboSense E1R | Solid-state | 30 m at 10% NIST reflectivity and 100 klux; 75 m maximum | Request specification | 120° × 90° | 260,000 points/s | Ethernet | Automotive Ethernet (T1) | On request | Quote |
| Hesai JT16 | Mini mechanical 360-degree lidar | 30 m | 16 | 360 x 40 deg | Request specification | Request specification | Request specification | On request | Quote |
| Livox Avia | Non-repetitive / repetitive scanning | 190 m at 10% / 230 m at 20% / 320 m at 80% reflectivity, 100 klx; 450 m at 80%, 0 klx | Request specification | 70.4° × 77.2° non-repetitive; 70.4° × 4.5° line scan | 240,000 single / 480,000 dual / 720,000 triple return points/s | Ethernet | Ethernet — port to confirm | On request | Quote |
| RoboSense Airy (96-channel configuration) | Spinning | 60 m maximum; 30 m at 10% reflectivity | 96 | 360° × 90° | 856,320 points/s | Ethernet | Conventional Ethernet | On request | Quote |
| Leishen C16 (16-channel) | Mechanical spinning | 150 m maximum in earlier datasheet; target reflectivity not specified | 16 | 360° × 30° (−15° to +15°), earlier datasheet | 320,000 single-return / 640,000 dual-return points/s | Ethernet | Ethernet — port to confirm | On request | Quote |
| Hesai AT128 | Semi-solid-state (hybrid) automotive lidar | 210 m at 10% reflectivity; current product-page typical value | 128 | 120 x 25.4 deg | 1,536,000 pts/s (single return) | Request specification | Request specification | On request | Quote |
| Hesai ATX | Semi-solid-state (hybrid) automotive lidar | 230 m @10% reflectivity | 256 | 120 x 20 deg | 3,840,000 pts/s max (single return) | Request specification | Request specification | On request | Quote |
| Hesai XT16 | Mechanical 360-degree lidar | 0.05-120 m | 16 | 360 x 30 deg | 320,000 pts/s (single return) | Request specification | Request specification | On request | Quote |
| Hesai XT32 | Mechanical 360-degree lidar | 0.05-120 m | 32 | 360 x 31 deg | 640,000 pts/s (single return) | Request specification | Request specification | On request | Quote |
| Hesai XT32M | Mechanical 360-degree lidar | 0.5-300 m | 32 | 360 x 40.3 deg | 640,000 pts/s (single return) | Request specification | Request specification | On request | Quote |
| Hesai JT128 | Hyper-hemispherical mini 3D lidar | 40 m @10% reflectivity (60 m max) | 128 | 360 x 189 deg | 1,150,000 pts/s (single return) | Request specification | Request specification | On request | Quote |
| RoboSense Helios 16 | Mechanical 360-degree lidar | 150 m (110 m @10% NIST) | 16 | 360 x 30 deg (-15 to +15) | 288,000 pts/s single / 576,000 pts/s dual | Ethernet | Automotive Ethernet (T1) | On request | Quote |
| RoboSense Helios 32 | Mechanical 360-degree lidar | 150 m (110 m @10% NIST) | 32 | 360 x 26 deg (H32F26) or 360 x 70 deg (H32F70) | 576,000 pts/s single / 1,152,000 pts/s dual | Ethernet | Automotive Ethernet (T1) | On request | Quote |
| RoboSense E1 | Fully solid-state (flash) lidar | 30 m @10% reflectivity | Request specification | 120 x 90 deg | Request specification | Request specification | Request specification | On request | Quote |
| RoboSense MX | Semi-solid-state automotive lidar | 200 m | 126 lines (251-line equivalent in ROI) | 120 x 25 deg | Request specification | Request specification | Request specification | On request | Quote |
| Livox Mid-70 | Non-repetitive scanning | 90 m at 10% / 130 m at 20% / 260 m at 80% reflectivity, 100 klx | Request specification | 70.4° circular | 100,000 single / 200,000 dual return points/s | Ethernet | Ethernet — port to confirm | On request | Quote |
| Seyond Robin W | Semi-solid-state wide-FoV lidar | 0.1-150 m (70 m @10% reflectivity) | 192 vertical lines | 120 x 70 deg | >1,280,000 pts/s | Request specification | Request specification | On request | Quote |
| LSLIDAR C16 | Mechanical spinning | 150 m at 70% reflectivity; 100 m at 10% reflectivity (CN-V2.2-24.10.23) | 16 | 360° × 30° (−16° to +14°), CN-V2.2-24.10.23 | 320,000 single-return / 640,000 dual-return points/s | Ethernet | Conventional Ethernet | On request | Quote |
| LSLIDAR C32 | Mechanical 360-degree lidar | Request specification | 32 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| LSLIDAR C32W | Mechanical 360-degree lidar | Request specification | 32 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| LSLIDAR CH32R | Hybrid solid-state blind-spot lidar | Request specification | 32 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| LSLIDAR CH16R | Hybrid solid-state blind-spot lidar | Request specification | 16 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| Benewake TF03 | Single-point ToF lidar | 0.1-180 m | Request specification | Request specification | Request specification | UART / CAN / RS-485 | UART | On request | Quote |
| Benewake AD2-S-X3 | Semi-solid-state automotive lidar | 300 m @10% reflectivity | 256 | Request specification | Request specification | Ethernet | Automotive Ethernet (T1) | On request | Quote |
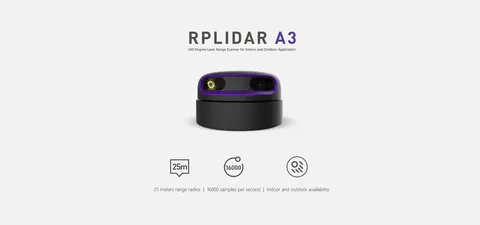
| SLAMTEC RPLIDAR A3 | Triangulation 2D SLAM lidar | 25 m (white target, enhanced mode) / 20 m outdoor mode | Request specification | Request specification | Request specification | UART | UART | On request | Quote |
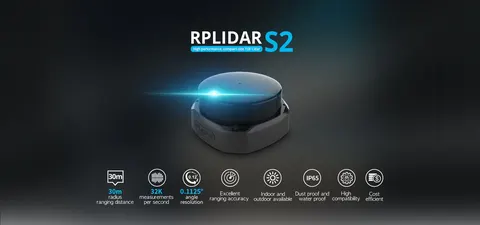
| SLAMTEC RPLIDAR S2 | ToF 2D SLAM lidar | 0.05-30 m (90% reflectivity); up to 50 m on S2P | Request specification | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| SLAMTEC RPLIDAR S2E | ToF 2D SLAM lidar | Request specification | Request specification | Request specification | Request specification | Ethernet | Ethernet — port to confirm | On request | Quote |
| ZVISION ZVISION NZ1 | Wide-angle 3D lidar | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| ZVISION ZVISION EZ6 | SPAD-based solid-state lidar | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| ZVISION ZVISION EZ5 | SPAD-based solid-state lidar | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| WanJi 8L-LiDAR | Mechanical multi-line lidar | Request specification | 8 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| WanJi 16L-LiDAR | Mechanical multi-line lidar | Request specification | 16 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| WanJi 32L-LiDAR | Mechanical multi-line lidar | Request specification | 32 | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| Livox Mid-360S | Non-repetitive scanning | 40 m at 10% reflectivity, 100 klx (typical); 100 m cut-off | Request specification | 360° horizontal; −7° to +52° vertical (typical) | 200,000 points/s (first return) | Ethernet | Ethernet — port to confirm | On request | Quote |
| Livox Avia 2 | Non-repetitive scanning; normal / focus modes | Normal: 400 m at 5%; focus: ≥800 m at 10% reflectivity (100 klx) | Request specification | 80° × 80° normal; 15° × 15° focus | 350,000 points/s normal; 100,000 points/s focus | Ethernet | Ethernet — port to confirm | On request | Quote |
| Livox Avia 2 NF | Non-repetitive scanning | Normal: 400 m at 5%; Focus: ≥800 m at 10% reflectivity, 100 klx | Request specification | 80° × 80° Normal; 15° × 15° Focus | 350,000 points/s Normal; 100,000 points/s Focus | Ethernet | Ethernet — port to confirm | On request | Quote |
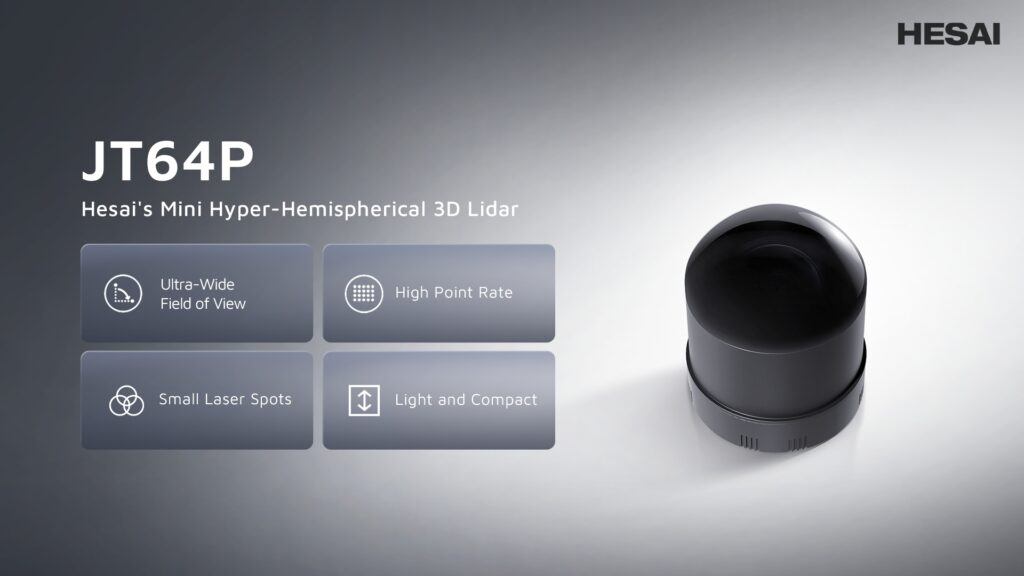
| Hesai JT64P | Spinning | 20 m at 10% reflectivity, all channels; instrumented interval 0–60 m | 64 | 360° horizontal; 95° vertical projection per J09 manual (−4.4° to 88.7°) | 499,500 single / 999,000 dual valid points/s (J09-260720) | Ethernet | Conventional Ethernet | On request | Quote |
| SLAMTEC RPLIDAR C1 | Spinning | 0.05–12 m at 70% reflectivity; 0.05–6 m at 10% | Single 2D scan plane | 360° azimuth; published scan-field flatness 0°–1.5° | 5,000 samples/s | UART | UART | On request | Quote |
| Livox Mid-360L | Non-repetitive scanning | 45 m at 10% reflectivity, 100 klx, typical; strongest near lower vertical FOV | Request specification | 360° horizontal × 44° vertical (−10° to +34°, typical) | 100,000 points/s (first return) | Ethernet | Ethernet — port to confirm | On request | Quote |
| Livox Tele-15 | Non-repetitive scanning | 320 m at 10% / 500 m at 50% reflectivity, 100 klx | Request specification | 14.5° horizontal × 16.2° vertical | 240,000 points/s first or strongest return; 480,000 dual return | Ethernet | Ethernet — port to confirm | On request | Quote |
| Livox HAP (TX) | Non-repetitive scanning | 150 m at 10% reflectivity, 100 klx | Request specification | 120° horizontal × 25° vertical | 452,000 points/s (first or strongest return) | Ethernet | Conventional Ethernet | On request | Quote |
| Livox HAP (T1) | Non-repetitive scanning | 150 m at 10% reflectivity, 100 klx | Request specification | 120° horizontal × 25° vertical | 452,000 points/s (first or strongest return) | Ethernet | Automotive Ethernet (T1) | On request | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
Compare the mounting geometry, horizontal and vertical field of view, minimum detection distance and occlusion for your route. Use the exact sensor datasheet and a scene trial to evaluate rotating or solid-state coverage.
Objects inside the sensor's minimum measurement distance may not produce usable range data. Check the exact model's blind zone, mounting position and near-field coverage for docking and close obstacle detection.
Request the exact IMU specification, ROS or ROS 2 driver, supported firmware and time-synchronization method. Confirm whether the quoted unit includes these features and which mapping stack has been tested.