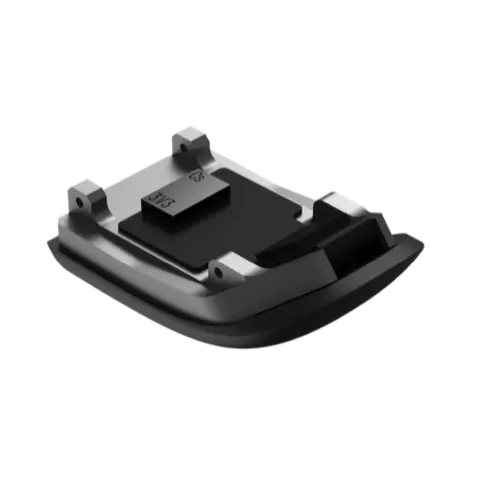
- Dimensions
- 27.9 × 25.7 × 14.4 mm
- Sensor form
- Multidimensional fingertip tactile sensor
- Default force ranges
- Normal 0–25 N; tangential ±10 N; adjustable
Robot Tactile Sensors from China
Compare piezoresistive, magnetic, and visuotactile sensors for dexterous hands and grippers by taxel density, force range, sampling rate, and interface.
As of October 2026, this catalog lists 6 models from 3 manufacturers, 1 of them with specifications matched line by line to the cited manufacturer documents. Filter by the requirements below, then request a quotation for the exact configuration.
Choose a manufacturer or product type, then narrow the specifications.
- Sensor principle
- Vision-based tactile sensing
- Sensing density
- 40,000 sensing units/cm²
- Integration context
- Contact feedback for robotic grippers
- Sensor structure
- Independent sensing unit
- Force sensing
- Three-dimensional force
- Communication
- IIC / I²C
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quoteCompare 6 matching models
| Model | Sensing technology | Quote |
|---|---|---|
| PaXini PX6AX-GEN2-DP-M2826 | Request specification | Quote |
| Daimon Robotics DM-Tac W | Request specification | Quote |
| Tashan TS-F-A | Request specification | Quote |
| Daimon Robotics DM-Tac G | Request specification | Quote |
| PaXini PX-6AX GEN1 | Multi-dimensional Hall-array tactile sensor | Quote |
| PaXini PX-6AX GEN3 | Multi-dimensional Hall-array tactile sensor | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
Tactile Sensors FAQ
How do piezoresistive, magnetic/Hall, and vision-based tactile sensors differ?
Flexible piezoresistive arrays offer thin conformable coverage for finger pads and palms, magnetic/Hall sensors measure 3-axis normal and shear forces with low hysteresis, and GelSight-style visuotactile sensors capture micron-scale surface geometry.
Can tactile sensors be ordered pre-integrated onto a dexterous hand?
Several hand manufacturers offer factory-integrated tactile fingertips and palms, while third-party tactile makers supply retrofit kits or custom FPC geometries for specific grippers and hands.
What should I check beyond headline taxel count on a tactile datasheet?
Verify whether the sensor measures normal force only (1D) or 3D normal-and-shear force, check minimum detectable force, overload limit, sampling rate for the full array, silicone wear-pad replacement, and ROS 2 packet format.