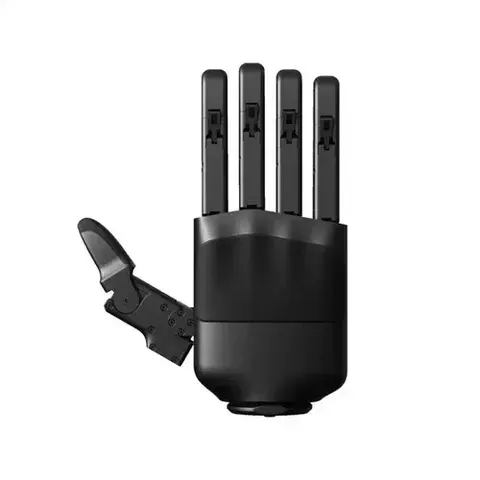
Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
AG-160-95 is a two-finger linkage gripper with 95 mm total stroke and 45–160 N adjustable force per jaw. Its 3 kg recommended-workpiece reference depends on friction, fingertip geometry and motion; robot mounting and communication options require configuration.
Sourcebotics selection notes, based on the published documentation.
| Product type | Industrial adaptive electric gripper |
| Finger / jaw count | 2 (mechanically coupled) |
| Controlled motion | One coupled grasp command controls the symmetric finger pair; total mechanical and active DOF are not enumerated in the reviewed documentation |
| Grip force (per jaw) | 45–160 N |
| Total stroke | 95 mm |
| Recommended workpiece limit | 3 kg maximum recommended under pure-friction gripping (coefficient 0.2, safety factor 4); center-of-mass offset and motion must be assessed |
| Weight | 1 kg |
| Dimensions | 184.6 × 162.3 × 67 mm (CN-2025.08 configuration) |
| Position repeatability | ±0.03 mm position repeatability (manufacturer specification) |
| Full-stroke opening / closing | 0.9 s / 0.9 s (full-stroke opening / closing; catalog reference, not an application cycle guarantee) |
| Drive mechanism | Screw-nut drive with adaptive linkage |
| Independent speed adjustment | Not shown as supported in CN-2025.08; operation manual relates motion speed to gripping-force setting |
| Communication | Standard: Modbus RTU (RS485), Digital I/O (2 inputs, 2 outputs); optional via external converter or customization: TCP/IP, USB 2.0, CAN 2.0A, PROFINET, EtherCAT |
| Voltage | 24 V DC ±10% |
| Rated / peak supply current | 0.8 A / 1.5 A |
| Ingress protection | IP54 |
| Recommended environment | 0–40 °C; relative humidity below 85% |
| Vertical static allowable load | Fz 300 N vertical static allowable load, using the catalog axis diagram; not a lifted-workpiece payload |
| Allowable external load moments | Mx 4.75 N·m; My 4.75 N·m; Mz 4.75 N·m, using the catalog axis diagram; allowable external load moments |
Manufacturer specifications for the listed model. Confirm options, operating conditions and integration requirements in your configuration-specific quotation.
DH-Robotics develops electric grippers, dexterous hands and motion components. Its Shenzhen sourcing contact supports selection across parallel, adaptive and rotating designs. Specify the exact gripper, fingers, cable and controller interface; compatibility and protection ratings vary by configuration.
Manufacturer and distributor references for model selection and technical review.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationIt is an industrial adaptive linkage gripper with two coupled fingers. The adaptive linkage follows workpiece shape through a shared grasp command. Formal total and active joint counts are not established in the reviewed documents.
No. The 3 kg reference assumes pure-friction gripping, coefficient 0.2 and safety factor 4. Fingertip geometry, center of mass, contact material and motion must be assessed. Fz and allowable Mx/My/Mz loads are separate structural limits.
Quote the native Modbus RTU/RS485 configuration and the required I/O polarity, hardware revision and cable. Other fieldbuses need the listed external converter or custom configuration. Request robot-specific plugins and a USB-to-RS485 adapter separately; the PC setup utility is not proof of an open SDK or tested integration.
The current catalog does not mark independent speed adjustment as supported for this model, and the operation manual relates motion speed to force setting. Check the required cycle at the intended force, part geometry and controller version.
Considering DH-Robotics AG-160-95 Adaptive Two-Finger Gripper? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk