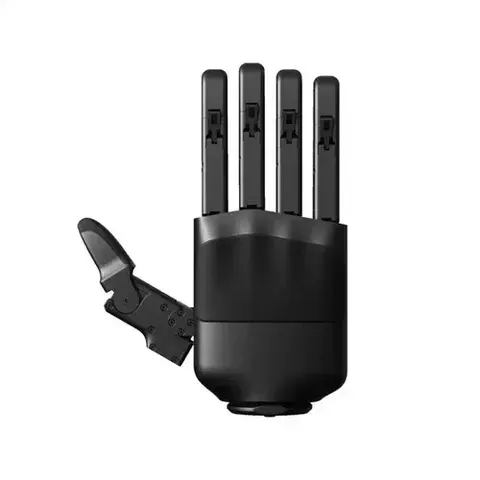
Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
Three-finger adaptive gripper switching between parallel and centric modes with 106 mm and 122 mm strokes, 10-65 N per-jaw force and 1.8 kg payload. Standard TCP/IP module and optional EtherCAT enable direct cobot control.
| Fingers | 3 |
| Grip Force | 10-65 N per jaw |
| Stroke | 106 mm parallel / 122 mm centric |
| Payload | 1.8 kg |
| Weight | 1.68 kg |
| Repeatability | +/-0.03 mm |
| Communication | TCP/IP standard; optional EtherCAT |
| Voltage | 24 VDC |
Manufacturer specifications for the listed model. Confirm options, operating conditions and integration requirements in your configuration-specific quotation.
DH-Robotics develops electric grippers, dexterous hands and motion components. Its Shenzhen sourcing contact supports selection across parallel, adaptive and rotating designs. Specify the exact gripper, fingers, cable and controller interface; compatibility and protection ratings vary by configuration.
Manufacturer and distributor references for model selection and technical review.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationConsidering DH-Robotics DH-3 Three-Finger Adaptive Gripper? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk