UnitreeDex5-1
- Degrees of freedom
- 20 total; 16 active
- Hand mass
- 1100 g
- Fingertip force
- 10 N
Price on request
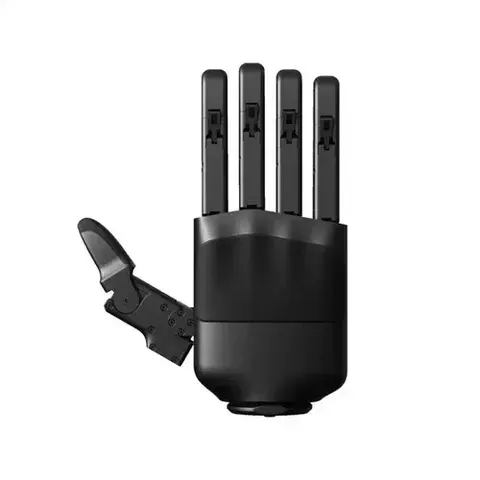
Five-finger hand with six controlled motions and twelve moving joints. The RH56DFTP tactile series combines force feedback with tactile sensing on the fingertips, pads and palm for contact-aware grasp development.
Sourcebotics selection notes, based on the published documentation.
| Controlled DOF | 6Reference ↗ |
| Moving joints | 12Reference ↗ |
| Fingertip repeatability | ±0.2 mmReference ↗ |
| Force sensors | 6; resolution 0.1 NReference ↗ |
| Tactile package | 5–17 sensors by configuration; fingertips, pads and palmReference ↗ |
| Five-finger gripping force | 30 N (manual terminology; not a per-fingertip payload)Reference ↗ |
| Power | 24 V DCReference ↗ |
| Communication choices | Modbus TCP + CAN 2.0, or Modbus TCP + RS-485Reference ↗ |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
Inspire Robots develops dexterous hands, micro linear servo actuators and electric grippers. Founded in Beijing in 2016, it offers multiple hand and actuator families with different sensing, wrist and interface configurations. Specify the exact model and supplied documentation before comparing a procurement quote.
Manufacturer and distributor references for model selection and technical review. Latest reference check: September 7, 2026.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationSpecify left or right hand, tactile coverage and the CAN or RS-485 wrist configuration.
Confirm the wrist drawing, force terminology and loaded grasp test for the objects in your application.
Considering Inspire Robots RH56DFTP (tactile series)? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk