Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
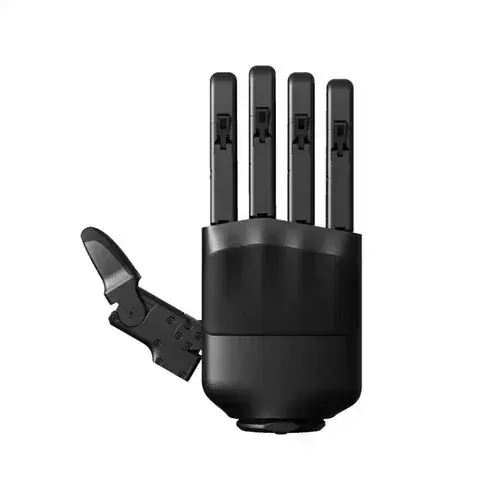
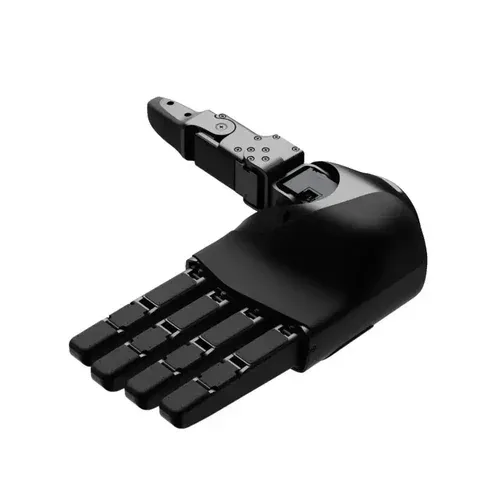
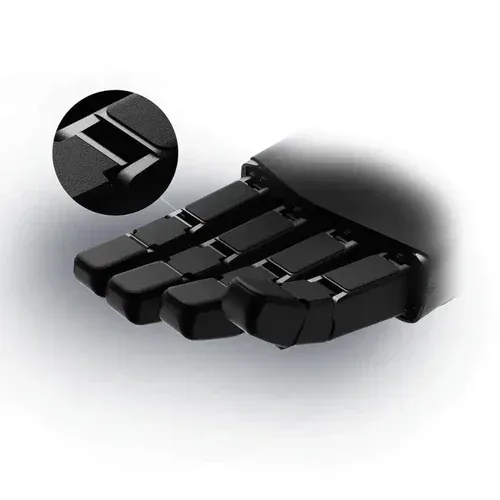
Five-finger development hand with 20 total degrees of freedom, including 16 active motions. This entry covers the base Dex5-1; the separate Dex5-1P adds pressure-sensing arrays. Both configurations are listed at 1,100 g on the manufacturer comparison.
Sourcebotics selection notes, based on the published documentation.
| Degrees of freedom | 20 total; 16 activeReference ↗ |
| Hand mass | 1100 gReference ↗ |
| Fingertip force | 10 NReference ↗ |
| Fingertip repeatability | ±1 mmReference ↗ |
| Dimensions, flat hand | 217.3 × 127.5 × 72.1 mm; final version may varyReference ↗ |
| Minimum grip diameter | 10 mmReference ↗ |
| Pressure-sensor package | Base Dex5-1: none listed; Dex5-1P: 12 arrays / 94 sensorsReference ↗ |
| Interface / communication rate | USB 2.0 / 1000 HzReference ↗ |
| Operating supply | 24–60 V DCReference ↗ |
| Palm-down grasp load | 3.5 kg at room temperature, gripping a 5 cm round hard objectReference ↗ |
| Palm-left grasp load | 4.5 kg at room temperature, gripping a 5 cm round hard objectReference ↗ |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
Unitree develops quadruped and humanoid robots, manipulators and core components including actuators and LiDAR. Its public resources support research and application development across these product families. The company listed on the Shanghai Stock Exchange STAR Market in August 2026 under code 688836.
Manufacturer and distributor references for model selection and technical review. Latest reference check: September 8, 2026.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationThat package belongs to Dex5-1P. This listing is for the base Dex5-1, so request the P variant explicitly if required.
The 4.5 kg figure is for palm-left grasping of a 5 cm round hard object at room temperature. Other objects and orientations require testing.
Considering Unitree Dex5-1 Five-Finger Dexterous Hand? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk