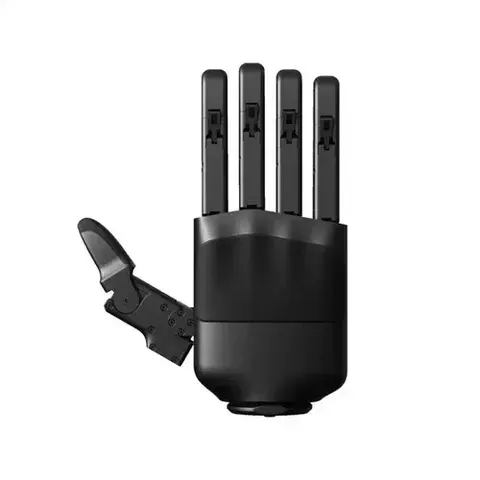
Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
Four-finger manipulation hand combining 13 active degrees of freedom, 1,140 tactile processing units and an 8 MP palm camera. Suitable for evaluating visual and tactile feedback together in grasping and manipulation workflows.
Sourcebotics selection notes, based on the published documentation.
| Active degrees of freedom | 13Reference ↗ |
| Fingers | 4Reference ↗ |
| Fingertip force | 15 NReference ↗ |
| Payload | 5 kgReference ↗ |
| Maximum grasp diameter | 15 cmReference ↗ |
| Tactile processing units | 1,140 ITPU GEN2 unitsReference ↗ |
| Tactile signal channels | 3,420Reference ↗ |
| Palm camera | 8 MPReference ↗ |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
PaXini develops Hall-effect tactile and force-sensing products, dexterous hands, humanoid robots and embodied-data tools. Its current portfolio includes PX6AX sensors, DexH13 and TORA platforms. Buyers should verify the exact sensor generation, hand configuration, interface and the definitions used for sensing units and signal channels.
Manufacturer and distributor references for model selection and technical review. Latest reference check: September 7, 2026.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationConfirm the controller, bus protocol and supported access to tactile and camera streams.
Define grasp geometry, load, required control rate and the demonstration data to include with the quotation.
Considering PaXini DexH13 GEN2? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk