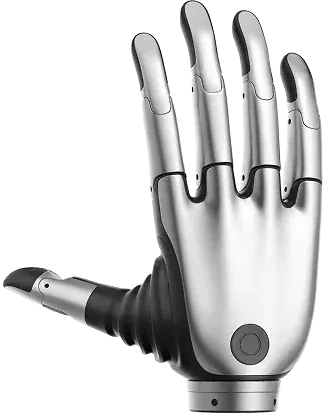
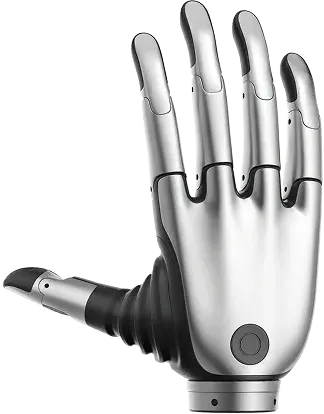
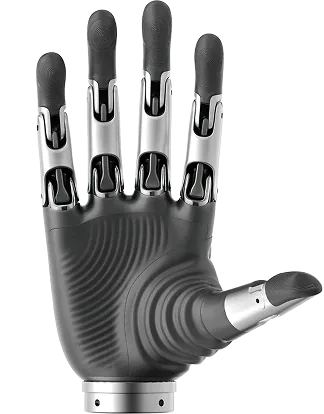
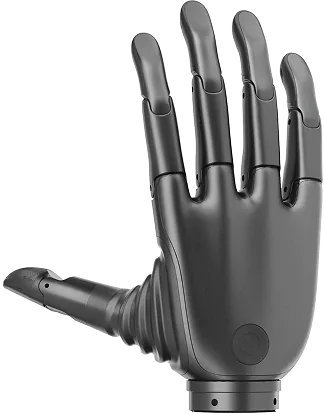
BrainCo Revo2 BASIC Bionic Dexterous Hand

BASIC hand with 11 total DoF, 6 active joints and 6 motors. It uses 12–28 V, supports RS485/CAN FD mode selection and omits tactile modules. The published ≥20 kg figure is a static-load reference.

Price on request
Total / active DoF11 / 6
Motors6
Supply (BASIC)12–28 V

Sourcebotics selection notes, based on the published documentation.

Application fit

  • Position/current-control experiments that do not require fingertip tactile data.

Integration planning

  • Confirm BASIC XRL/XRR hardware and the matching RS485/CAN FD firmware. These protocols are selected by a wrist DIP switch.
  • Request the BASIC wrist drawing and include any USB debugging adapter and power supply in the purchase scope; the manual treats debugging adapters as optional.
  • Use 12–28 V for this BASIC reference; the 12–64 V and EtherCAT entries belong to PRO/TOUCH.

Selection considerations

  • The 383 g figure excludes the wrist; include the final wrist and adapter mass in the arm calculation.
  • Request posture, holding duration and contact geometry behind the static-load figure before defining a manipulation acceptance test.

Technical specifications

Product documentation
BASIC MANUFACTURER-REPORTED SPECIFICATIONS
Total / active DoF11 / 6Reference ↗
Motors6Reference ↗
Fingers5Reference ↗
Weight383 g (without wrist)Reference ↗
Hand length160 mm (palm base to middle fingertip)Reference ↗
Grip Force≥50 N power grasp; ≥15 N pinchReference ↗
Static-load reference≥20 kg static load (English manual label); test posture and duration not specified.Reference ↗
Tactile sensingNot fitted on BASICReference ↗
CommunicationRS485 and CAN FD (DIP-switch selection; one mode at a time)Reference ↗
Voltage12–28 V (BASIC)Reference ↗
Repetitive control precision0.1° (angular)Reference ↗
Full opening / closing time≤0.65 sReference ↗
Operating noise≤50 dB at 0.5 mReference ↗
Operating temperature−10 to 40 °CReference ↗

Manufacturer specifications for the listed model. Confirm options, operating conditions and integration requirements in your configuration-specific quotation.

Supplier

Hangzhou BrainCo Technology Co., Ltd. 杭州强脑科技有限公司
Hangzhou, Zhejiang · est. 2015 · 500–1,000 employees

BrainCo grew out of a Harvard innovation lab and is a leading brain-machine interface and bionic limb company. Its Revo dexterous hands transfer prosthetics-grade tendon actuation to humanoid robots, offering 11 degrees of freedom, 383 g mass and grip force above 50 N.

View profile

Configuration & quotation

Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.

Price range (USD)Price on request
MOQ1
Lead time15-30 days

Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.

Discuss this configuration

FAQ

Does BASIC accept 64 V or include EtherCAT and tactile sensing?

No. The BASIC column in the English and Chinese documentation specifies 12–28 V, RS485/CAN FD and no tactile module. The higher voltage and EtherCAT entries belong to PRO/TOUCH.

Can BASIC manipulate any 20 kg object?

The English V2.1 manual labels ≥20 kg as Static Load; the live English page uses Max Payload and the Chinese sources use whole-hand load. A posture, duration and dynamic handling test is not provided. Treat it as a manufacturer static-load reference and obtain task-specific limits.

What mass and precision do the published figures describe?

383 g excludes the wrist. The 0.1° specification is angular repetitive control precision, not fingertip repeatability in millimetres.

Related models

Considering BrainCo Revo2 BASIC Bionic Dexterous Hand? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.

Request a quote

— The Sourcebotics sourcing desk

Chat