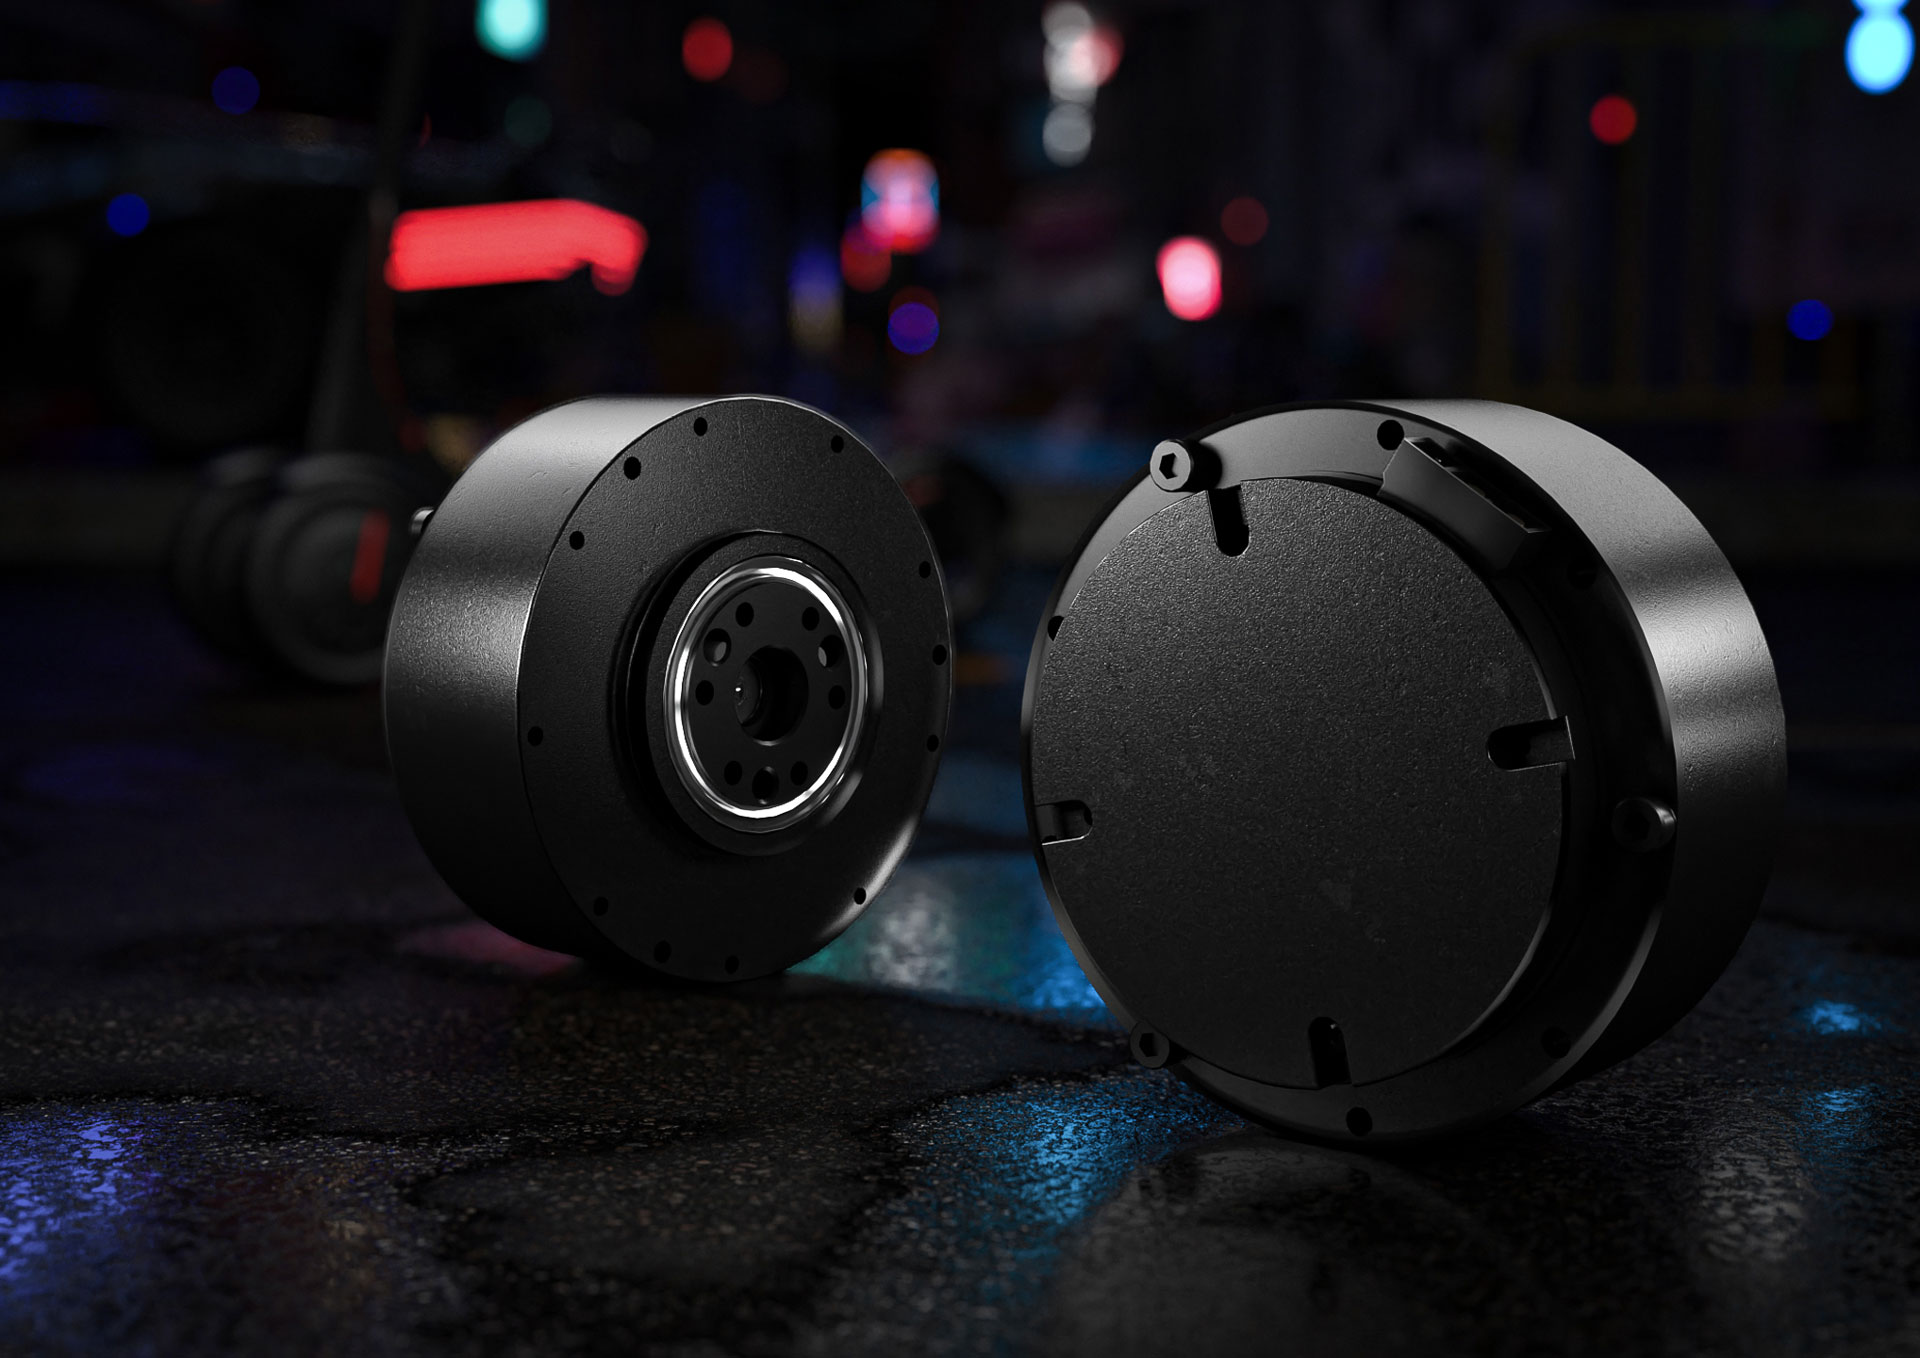
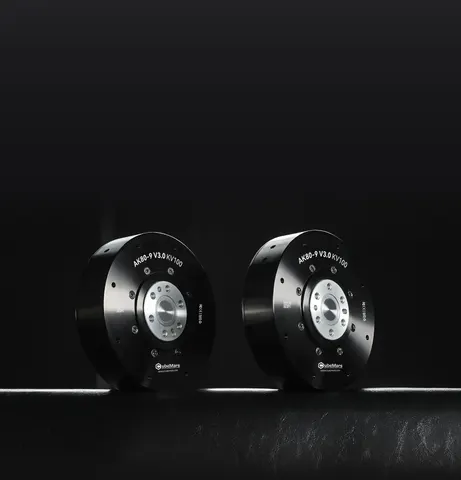
RobStride RS02 CAN Joint Actuator
RobStride RS02 combines a motor, 7.75:1 planetary reducer and CAN drive. It operates at 48 V nominal supply with 17 N·m peak torque and 2 magnetic encoders. Compare thermal mounting, firmware and the required configuration before ordering.
Price on requestRequest a quotation for the selected hardware and firmware, cables, CAN adapter, quantity, destination and support requirements. Freight, taxes and delivery terms are itemized for your order.
Peak Torque17 N·m; short-duration load
Nominal supply48 VDC
Encoder arrangement2 magnetic encoders; 14-bit single-turn absolute resolution
Choosing this model
Read the product documentationSourcebotics selection notes, based on the published documentation.
Application fit
- CAN joint integration requiring 48 V nominal supply, a 7.75:1 planetary reducer and 2 magnetic encoders.
- Mechanism development with a defined load, speed, duty cycle and thermal mounting arrangement.
Integration planning
- October series table: 7 N·m at 100 rpm with a 150 × 150 mm aluminium plate. Model manuals: 6 N·m at 100 rpm with a 260 × 280 mm plate. Select against the rating and thermal setup specified for the delivered revision.
- October series table: 15–60 VDC. Model manuals and webpage: 24–60 VDC. Select the supply range against the delivered hardware revision.
- Python examples require Python 3.10 or newer, Linux SocketCAN and a compatible CAN adapter. Specify the adapter, CAN bitrate, motor IDs, firmware and selected protocol in the integration brief. Private CAN operation-control frames, CANopen and the separate MIT protocol use different commands.
Selection considerations
- October series table: 418 ±3 g; Chinese manual labelled 261009: 405 ±3 g; English manual labelled 260713: 380 ±3 g; manufacturer webpage: 405 ±5 g. Specify the delivered revision and installed mass in the quotation.
- The base-model webpage lists IP52 and offers IP67 customization. RS02-IP67 is listed separately by the manufacturer; specify the exact variant, connectors and protection requirements in the quotation.
- Include hardware revision, matching firmware, control mode, adapter, cables, mounting drawing and written warranty coverage in the purchase brief.
Buying & integration notes
RobStride RS02 combines a motor, 7.75:1 planetary reducer and CAN drive. It operates at 48 V nominal supply with 17 N·m peak torque and 2 magnetic encoders. Compare thermal mounting, firmware and the required configuration before ordering.
Select the actuator configuration
RS02 is the manufacturer’s short name for RobStride 02. RS02-IP67 is a separate model; specify the base RS02 or the required IP67 variant in the inquiry.
Match torque to the working cycle
October series table: 7 N·m at 100 rpm with a 150 × 150 mm aluminium plate. Model manuals: 6 N·m at 100 rpm with a 260 × 280 mm plate. Select against the rating and thermal setup specified for the delivered revision. Peak torque describes a short-duration load. Define the working speed, hold time, repeated-load cycle and ambient temperature for selection.
Plan power, mounting and clearance
Nominal supply is 48 VDC. October series table: 15–60 VDC. Model manuals and webpage: 24–60 VDC. Select the supply range against the delivered hardware revision. 7 Apk ±10% rated-load phase current; 23 Apk ±10% peak phase current. Size the power supply for the intended duty cycle, bus demands and regenerative-energy arrangement.
October series table: 418 ±3 g; Chinese manual labelled 261009: 405 ±3 g; English manual labelled 260713: 380 ±3 g; manufacturer webpage: 405 ±5 g. Specify the delivered revision and installed mass in the quotation. Manufacturer webpage: 78.5 × 78.5 × 45.5 mm; the series drawing labels a 41.5 mm axial dimension. Check the complete installed envelope against the supplied assembly drawing.
The base-model webpage lists IP52 and offers IP67 customization. RS02-IP67 is listed separately by the manufacturer; specify the exact variant, connectors and protection requirements in the quotation.
Specify control and software access
Python examples require Python 3.10 or newer, Linux SocketCAN and a compatible CAN adapter. Specify the adapter, CAN bitrate, motor IDs, firmware and selected protocol in the integration brief. Private CAN operation-control frames, CANopen and the separate MIT protocol use different commands. The Chinese manual labels additional MIT parameter commands as requiring firmware 0.2.3.32. Match the command set to the supplied firmware.
The Python source uses an MIT licence. For the ROS sample, obtain the applicable licence terms before redistribution and include the required software and adapter documentation in the order.
Prepare a comparable quotation
The October 9, 2026 manufacturer series table lists CNY 699. Use a configuration-specific Sourcebotics quotation for the actuator, adapter, cables, support, delivery terms, freight and taxes. Specify warranty duration, business-use coverage, support arrangements and delivery destination in the written quotation. The English model manual lists commercial use among warranty exclusions; obtain the terms applicable to your business purchase.
Prepare the load, speed, thermal mounting, hardware and software requirements with the robot procurement checklist
For actuator selection and quotation planning, read the joint-module buying guide
Technical specifications
Product documentationTORQUE, THERMAL MOUNTING AND POWER
| Rated torque by document | 7 N·m in the October series table; 6 N·m in model manuals, under their respective thermal conditionsReference ↗ |
| Thermal mounting | October series table: 7 N·m at 100 rpm with a 150 × 150 mm aluminium plate. Model manuals: 6 N·m at 100 rpm with a 260 × 280 mm plate. Select against the rating and thermal setup specified for the delivered revision.Reference ↗ |
| Peak Torque | 17 N·m; short-duration load, separate from continuous torqueReference ↗ |
| Nominal supply | 48 VDCReference ↗ |
| Supply range by document | October series table: 15–60 VDC. Model manuals and webpage: 24–60 VDC. Select the supply range against the delivered hardware revision.Reference ↗ |
| Phase current | 7 Apk ±10% rated-load phase current; 23 Apk ±10% peak phase current; separate from DC power-supply currentReference ↗ |
| No-load speed | 410 rpm ±10% at nominal supplyReference ↗ |
MECHANICS AND ENVIRONMENT
| Mass by document | October series table: 418 ±3 g; Chinese manual labelled 261009: 405 ±3 g; English manual labelled 260713: 380 ±3 g; manufacturer webpage: 405 ±5 g. Specify the delivered revision and installed mass in the quotation.Reference ↗ |
| Reduction ratio | 7.75:1Reference ↗ |
| Gear type | Planetary; machined steel gearingReference ↗ |
| Installation dimensions | Manufacturer webpage: 78.5 × 78.5 × 45.5 mm; the series drawing labels a 41.5 mm axial dimension. Check the complete installed envelope against the supplied assembly drawing.Reference ↗ |
| Encoder arrangement | 2 magnetic encoders; 14-bit single-turn absolute resolutionReference ↗ |
| Environmental protection | The base-model webpage lists IP52 and offers IP67 customization. RS02-IP67 is listed separately by the manufacturer; specify the exact variant, connectors and protection requirements in the quotation.Reference ↗ |
| Operating temperature | −20 to 50 °C; check the load and cooling arrangementReference ↗ |
CONTROL AND INTEGRATION
| CAN bitrate | 1 Mbps; use matching bus termination and adapterReference ↗ |
| Protocols | Private CAN, CANopen and a separate MIT protocol; select against the supplied firmwareReference ↗ |
| Development resources | Python examples require Python 3.10 or newer, Linux SocketCAN and a compatible CAN adapter. Specify the adapter, CAN bitrate, motor IDs, firmware and selected protocol in the integration brief. Private CAN operation-control frames, CANopen and the separate MIT protocol use different commands.Reference ↗ |
| MIT parameter commands | The Chinese manual labels MIT data-save, reporting, parameter-read and parameter-write commands as requiring firmware 0.2.3.32.Reference ↗ |
Manufacturer specifications for the listed model. Confirm options, operating conditions and integration requirements in your configuration-specific quotation.
Supplier
RobStride Dynamics Co., Ltd. 灵足时代(北京)科技有限公司
Beijing · est. 2024
Founded by former Xiaomi robotics engineers, RobStride designs integrated joint motors combining frameless torque motors, planetary reduction, encoder and drive. Aggressive pricing, such as a 120 Nm peak-torque module at consumer price levels, has made it a popular choice for humanoid and quadruped prototyping worldwide.
Downloads
Manufacturer RS-series specifications — October 9, 2026
Model tables, mounting drawings, thermal conditions and performance curves.
RS02 user manual — English
File labelled 260713; check the operating conditions and protocol for the supplied unit.
RS02 user manual — Chinese
File labelled 261009; model specifications, control commands and firmware requirements.
RS02 mounting model — STEP
Manufacturer CAD file; match the drawing and model revision to the supplied unit.
Manufacturer Python CAN examples
Python 3.10+, Linux SocketCAN and model-specific frame conversion; MIT licence.
Manufacturer ROS examples
Humble setup examples; specify the adapter and firmware and obtain licence terms before redistribution.
Product documentation
Manufacturer and distributor references for model selection and technical review. Specification sources last reviewed: October 14, 2026.
Configuration & quotation
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Price range (USD)Price on request
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationFAQ
How should I compare rated and peak torque?
October series table: 7 N·m at 100 rpm with a 150 × 150 mm aluminium plate. Model manuals: 6 N·m at 100 rpm with a 260 × 280 mm plate. Select against the rating and thermal setup specified for the delivered revision. Peak torque is a short-duration load; agree the required working cycle and load conditions for your configuration.
Which mass and supply range should be used for integration?
October series table: 418 ±3 g; Chinese manual labelled 261009: 405 ±3 g; English manual labelled 260713: 380 ±3 g; manufacturer webpage: 405 ±5 g. Specify the delivered revision and installed mass in the quotation. October series table: 15–60 VDC. Model manuals and webpage: 24–60 VDC. Select the supply range against the delivered hardware revision.
What should be specified for CAN and software integration?
Python examples require Python 3.10 or newer, Linux SocketCAN and a compatible CAN adapter. Specify the adapter, CAN bitrate, motor IDs, firmware and selected protocol in the integration brief. Private CAN operation-control frames, CANopen and the separate MIT protocol use different commands. Additional MIT parameter commands are labelled for firmware 0.2.3.32 in the Chinese manual. Specify the matching firmware and command set.
What is included in the quotation?
Specify the actuator revision, quantity, cables, CAN adapter, mounting requirements, documentation, support and destination. Specify warranty duration, business-use coverage, support arrangements and delivery destination in the written quotation. The English model manual lists commercial use among warranty exclusions; obtain the terms applicable to your business purchase.
Related models
Considering RobStride RS02 CAN Joint Actuator? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk