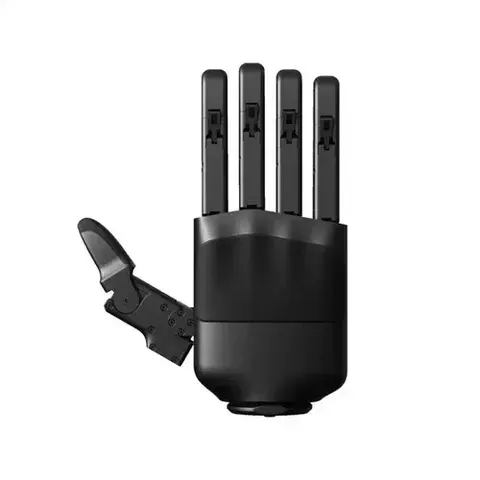


Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
Eleven-joint, six active DoF industrial dexterous hand weighing 545 g with 184 mm middle finger reach. Hook grip carries 294 N, single fingers 98 N, and UART, RS485 or CAN ModBus-RTU control ships with SDK, ROS, ROS 2, and URDF support.
| DoF | 11 joints |
| Active DoF | 6 |
| Fingers | 5 |
| Grip Force | >=4.41 N per fingertip, >=9.8 N thumb |
| Payload | 294 N hook grip (30 kg); 98 N per finger; 78.4 N fingertip extension |
| Weight | 545 +/-5 g |
| Communication | UART / RS485 / CAN, ModBus-RTU |
| Repeatability | +/-1 mm |
| Closing Time | <=0.7 s |
| Material | Zinc alloy and aluminium alloy |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
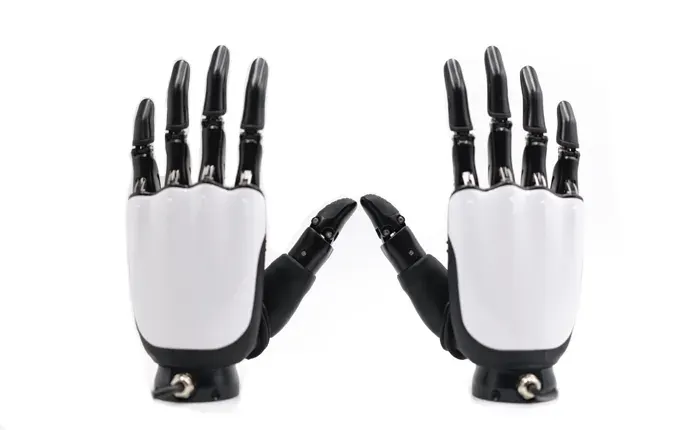
OYMotion combines surface-EMG gesture recognition with bionic hand engineering. Its ROHAND series offers six active degrees of freedom across eleven joints, fingertip force feedback from 0.1 N, and UART, RS485 and CAN interfaces with ROS, ROS 2, and URDF support for volume robot programmes.
Manufacturer and distributor references for model selection and technical review.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination.
Discuss this configurationConsidering OYMotion ROHAND ROH-A002 Five-Finger Dexterous Hand? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk