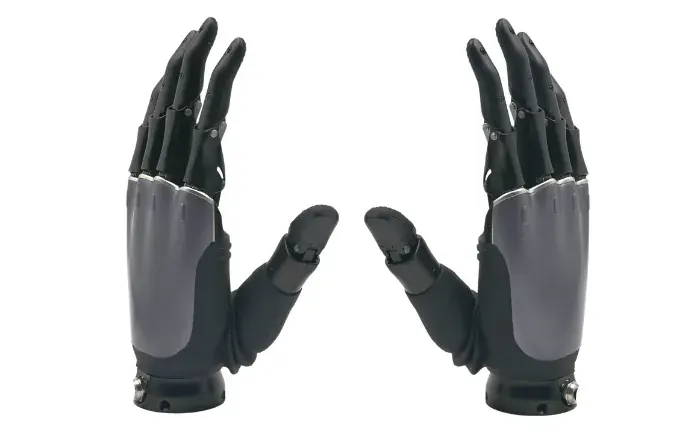
OYMotion ROHAND ROH-AP002 Dexterous Hand
Five-finger ROH-AP002 with 11 movable joints, 6 active DoF and 6 motor drivers. V1.0.2 documents finger force sensing and a 55-site palm matrix; interface, power and load limits need their stated configuration and posture.
Price on request
Movable joints11
Active DoF6
Fingers5
Choosing this model
Read the product documentationSourcebotics selection notes, based on the published documentation.
Application fit
- Force-feedback manipulation experiments requiring finger and palm sensing.
Integration planning
- Specify LB/RB handedness and the -C suffix if CAN is required. Confirm the interface-specific voltage and connector pinout before selecting the power supply.
- Use the model-specific ROS/ROS2 and serial examples as an integration starting point; confirm the target environment and SDK release.
- Request the mechanical drawing for the shipped revision: English and Chinese V1.0.2 manuals disagree on palm width and thumb-tip-to-wrist distance.
Selection considerations
- The 30 kg figure is passive support with four fingers bent, not an arbitrary dynamic lifting payload.
- Do not interpret the 55 palm sites as the whole hand’s total taxel count, or the 0.1 N normal-range lower bound as force resolution.
Technical specifications
Product documentationROH-AP002 DOCUMENTED FACTS AND SOURCE DIFFERENCES
| Movable joints | 11 (not an independently confirmed total DoF count)Reference ↗ |
| Active DoF | 6Reference ↗ |
| Motor drivers | 6Reference ↗ |
| Fingers | 5Reference ↗ |
| Weight | 626 ±5 g (including wrist)Reference ↗ |
| Hand length | 183 mm (middle fingertip to wrist)Reference ↗ |
| Palm width / thumb-tip-to-wrist | Unresolved: English V1.0.2 82 / 97 mm; Chinese V1.0.2 83 / 95 mmReference ↗ |
| Passive load | Maximum passive load: 30 kg with four fingers bent; 10 kg one finger bent; 8 kg one finger straight (V1.0.2).Reference ↗ |
| Active finger force | Non-thumb straight ≥0.45 kgf; bent ≥1.0 kgf; thumb ≥1.0 kgfReference ↗ |
| Full-travel time | 0.7 s finger flexion/extension; 0.7 s thumb rotation at maximum speedReference ↗ |
| Tactile sensing | Finger 3D force sensing; 11 × 5 palm matrix (55 sites, not a whole-hand count)Reference ↗ |
| Force measurement range | Normal 0.1–25 N; distal tangential 0.25–25 N (0.1 N is not declared resolution)Reference ↗ |
| Communication | Interface variants: UART, RS485 or CAN (-C suffix identifies CAN)Reference ↗ |
| Protocols | UART/RS485: SerialCtrl or Modbus RTU; CAN: CanSerialCtrlReference ↗ |
| Power supply | V1.0.2: RS485 12–24 V DC; CAN 12–48 V DC. Website and connector table show 24 V; confirm the exact interface/revision.Reference ↗ |
| Power definitions | Manual rated 48 W; website typical ≤15 W and standby ≤0.5 W; do not treat as equivalentReference ↗ |
| Repeat-positioning claim | Product listing claims ±0.05 mm repeat positioning; no corresponding test conditions or confirmation found in V1.0.2.Reference ↗ |
| Environment | −10 to 40 °C; maximum 85% RH; not waterproof (manual)Reference ↗ |
Manufacturer specifications for the listed model. Confirm options, operating conditions and integration requirements in your configuration-specific quotation.
Supplier
OYMotion Technologies Co., Ltd. 上海傲意信息科技有限公司
Shanghai · est. 2015 · 100–500 employees
OYMotion combines surface-EMG gesture recognition with bionic hand engineering. Its ROHAND series offers six active degrees of freedom across eleven joints, fingertip force feedback from 0.1 N, and UART, RS485 and CAN interfaces with ROS, ROS 2, and URDF support for volume robot programmes.
Downloads
ROH-AP002 User Manual V1.0.2 (English)
2026-04-23 revision; load postures, interface-specific voltage and force ranges.
ROH-AP002 用户手册 V1.0.2 (Chinese)
Same version; palm width and thumb-tip-to-wrist measurements differ from English.
Official ROH-AP002 development resources
Model-specific ROS/ROS 2 and serial examples. Confirm the supported hardware, firmware and host environment for your integration.
Current manufacturer product page
Web power definitions differ from manual rated power; confirm revision.
Product documentation
Manufacturer and distributor references for model selection and technical review.
Configuration & quotation
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Price range (USD)Price on request
MOQ1
Lead time20-40 days
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationFAQ
Does ROH-AP002 have six fingers or eleven active axes?
No. It has five fingers, eleven movable joints, six active DoF and six built-in motor drivers. The manual does not separately specify eleven independent DoF.
Does the 30 kg value mean it can dynamically lift a 30 kg object?
No. V1.0.2 describes a maximum passive load with four fingers bent. It separately lists 10 kg for one bent finger and 8 kg for one straight finger. Object contact, posture and dynamic handling need their own assessment.
Which interface and supply voltage apply?
The -C suffix identifies CAN hardware. V1.0.2 specifies RS485 12–24 V DC and CAN 12–48 V DC, but the product page and connector row state 24 V. The manual gives 48 W rated power; the page gives ≤15 W typical and ≤0.5 W standby. Confirm the exact interface, revision and power definition with the supplier.
Are 0.1 N resolution and ±0.05 mm repeatability confirmed by the manual?
The manual identifies 0.1 N as the lower bound of the normal-force measurement range, rather than resolution. Specify the product listing’s ±0.05 mm repeat-positioning figure together with its measurement conditions and numeric acceptance criteria in the purchase brief.
Why are some dimensions not presented as one number?
Both V1.0.2 manuals give 183 mm from middle fingertip to wrist. English gives 82 mm palm width and 97 mm thumb-tip-to-wrist; Chinese gives 83 mm and 95 mm. Request the drawing for the shipped revision before making a mount.
Related models
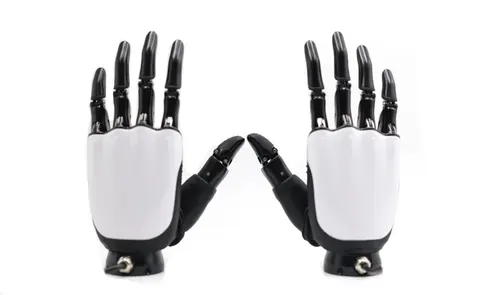
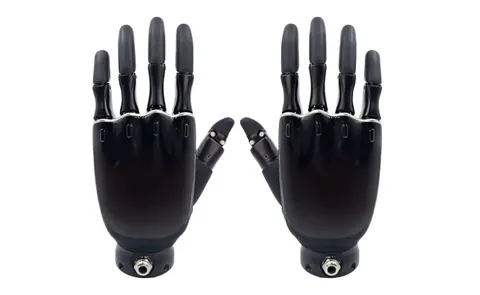
OYMotion ROH-AP003
- Fingers
- 5
- Tactile Sensing
- Melexis 3D tactile sensors
- Control
- Omnidirectional force control, adaptive grasping
Price on request
Considering OYMotion ROHAND ROH-AP002 Dexterous Hand? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk