Inspire RobotsRH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
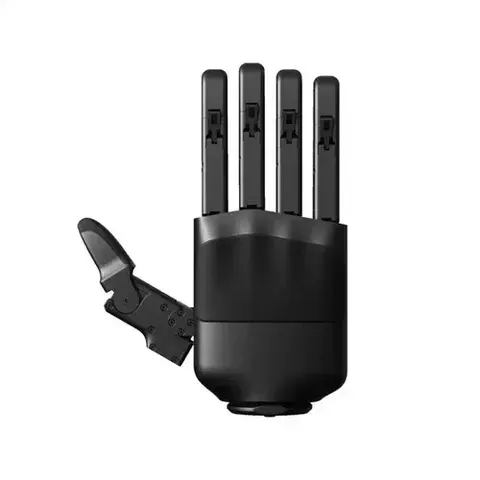
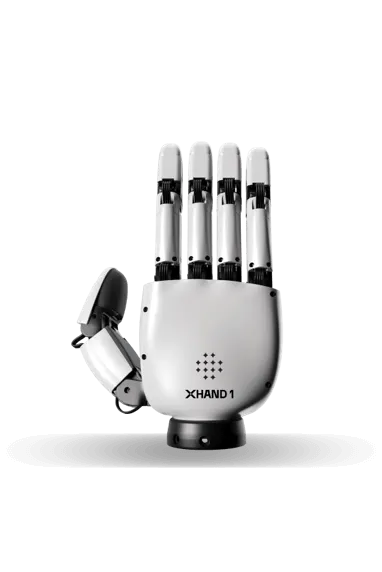
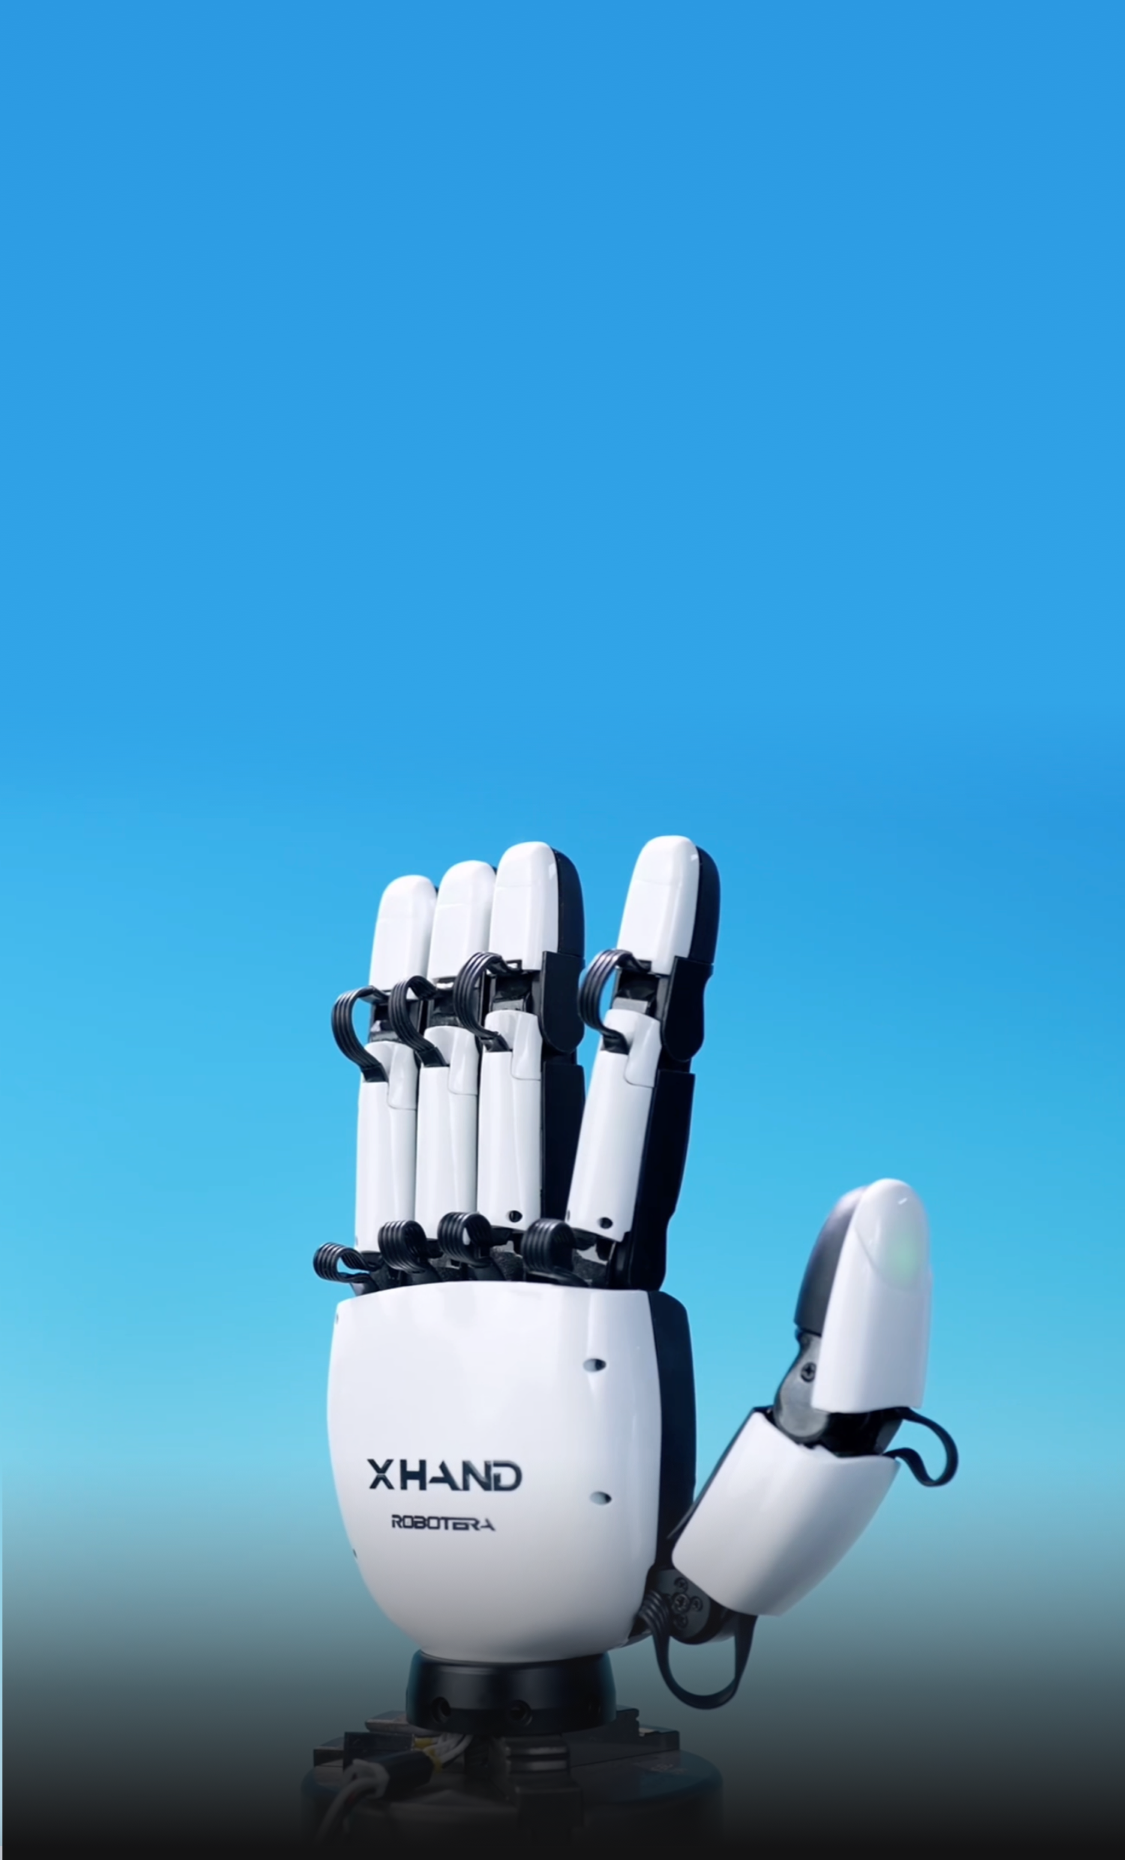
Five-finger hand with 12 independently driven degrees of freedom, including lateral index-finger motion. The manufacturer provides Linux and ROS development support; high-resolution tactile sensing is a configuration option.
Sourcebotics selection notes, based on the published documentation.
| Active degrees of freedom | 12; independently drivenReference ↗ |
| Weight | 1.1 kgReference ↗ |
| Dimensions | 190.36 × 94 × 47 mmReference ↗ |
| Maximum fingertip force | 15 NReference ↗ |
| Maximum whole-hand grip force | 80 NReference ↗ |
| Minimum grasp diameter | 16 mmReference ↗ |
| Index-finger lateral movement | ±15°Reference ↗ |
| Tactile option | More than 100 points per finger when equipped; 3D force and temperatureReference ↗ |
| Development resources | Linux SDK and ROS-compatible applicationsReference ↗ |
| Teleoperation options | Vision Pro, motion-capture gloves and visual mapping described in product briefReference ↗ |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
ROBOTERA develops humanoid platforms, dexterous hands and embodied AI in Beijing. Its current range distinguishes the L7 biped, Q5 wheeled platform, M7 upper-body platform and XHAND hand variants. Compare exact hardware, software access and documented task requirements before procurement.
Manufacturer and distributor references for model selection and technical review. Latest reference check: September 8, 2026.
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationSpecify handedness, tactile package, adapter and host system. Keep XHAND1 distinct from the Lite and Pro variants.
Its force and load figures describe different measures. Agree object shape, friction, palm orientation and the task test with the supplier.
Considering Robot Era XHAND1? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk