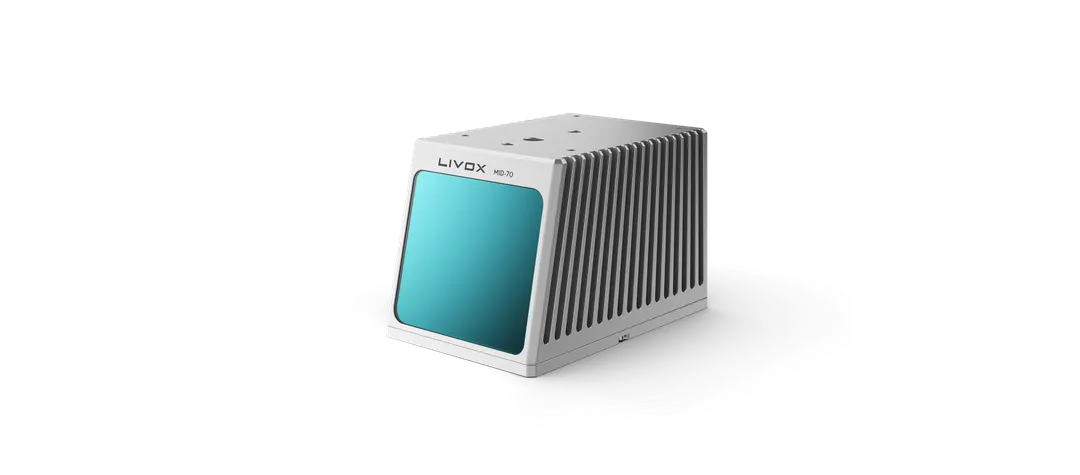
Livox Mid-70 Non-Repetitive Scanning LiDAR

Directional non-repetitive LiDAR with a 70.4° circular field of view and 90 m range at 10% reflectivity under 100 klx. MID-70 uses the original Livox SDK; its 8 W average power excludes substantially higher startup and cold-heating loads.

Price on requestRequest an itemized quotation for the selected configuration, accessories, support and delivery destination.
Range at 100 klx90 m at 10%; 130 m at 20%; 260 m at 80% reflectivity
Field of view70.4° circular
Point rate100,000 single / 200,000 dual return points/s

Sourcebotics selection notes, based on the published documentation.

Application fit

  • Forward and side perception on mobile robots.
  • Focused coverage where a circular viewing cone fits the installation.

Integration planning

  • The 35 W specification-table peak and up-to-40 W low-temperature discussion in manual v1.2 are both retained. Obtain a temperature-specific power budget for the delivered unit.
  • 10–15 V applies at the sensor; 9–30 V applies through Converter 2.0. The converter and cables are outside the sensor IP67 rating.
  • A 0.05 m reported blind zone does not establish precise ranging from that distance; 0.05–0.2 m returns are reference-only.

Selection considerations

  • Confirm the exact model, firmware, cable, power supply and host software in the quotation.
  • Manufacturer documentation establishes reference conditions; it does not replace application testing or confirm current availability.

Technical specifications

Product documentation
SENSING
Range at 100 klx90 m at 10%; 130 m at 20%; 260 m at 80% reflectivityReference ↗
Field of view70.4° circularReference ↗
Point rate100,000 single / 200,000 dual return points/sReference ↗
Range precision≤2 cm (1σ), 20 m, 30% reflectivity, 25°CReference ↗
Near-field precision≤3 cm (1σ), 0.2–1 m, 30% reflectivity, 25°C; 0.05–0.2 m reference-onlyReference ↗
INSTALLATION
Mass / dimensions580 g; 97 × 64 × 62.7 mmReference ↗
Interface / synchronization100 Mbps Ethernet; PTPv2, PPS, GPS (PPS + UTC)Reference ↗
Supply voltage10–15 V DC; 9–30 V DC with Converter 2.0Reference ↗
Power8 W average; manual lists 35 W peak and up to 40 W cold self-heatingReference ↗
Enclosure / temperatureIP67 sensor, excluding converter and cables; −20 to +65°CReference ↗
POWER AND SOFTWARE SCOPE
Power budget8 W average; manual specifications list 35 W peak, while the power section allows up to 40 W self-heating at −20 to 0°C; confirm the required supplyReference ↗
SDK / driver generationOriginal Livox-SDK (MID-70 device type 6), with the legacy ROS driver family. Do not substitute SDK2 or livox_ros_driver2 solely because both are Livox software.Reference ↗
Firmware referenceV10.10.0001; notes dated April 7, 2023; portal dated April 10Reference ↗

Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.

Supplier

Livox Technology Company Limited 览沃科技有限公司
Unknown · est. 2016

Livox develops LiDAR for mobile robotics, mapping and autonomous systems. Its website dates the brand to 2016. Select the exact MID-360, MID-360S or Avia variant and confirm its SDK, firmware, contracting entity and destination-specific service terms.

View profile

Configuration & quotation

Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.

Price range (USD)Price on request

Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.

Discuss this configuration

FAQ

How much power should the supply provide?

The web specification gives 8 W average. Manual v1.2 lists 35 W peak in its table and up to 40 W during −20 to 0°C self-heating, which lasts at least three minutes. Confirm the transient budget; do not design from 8 W alone.

Does the newer Livox ROS Driver 2 replace the original driver?

The reviewed original SDK explicitly defines MID-70. The newer driver2 supported-model list covers a different sensor family. A separate legacy livox_ros2_driver repository exists; confirm its SDK build and ROS distribution with the actual MID-70 before deployment.

Related models

Considering Livox Mid-70 Non-Repetitive Scanning LiDAR? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.

Request a quote

— The Sourcebotics sourcing desk

Chat