- Range
- 30 m at 90% reflectivity; 15 m at 10%
- Field of view
- 360° × 90° normal; 360° × 96° in negative-angle mode, with shorter range in the extra 6°
- Effective point rate
- 64,000 points/s; distinct from 128,000 raw samples/s
Livox Mid-360 Hemispherical LiDAR
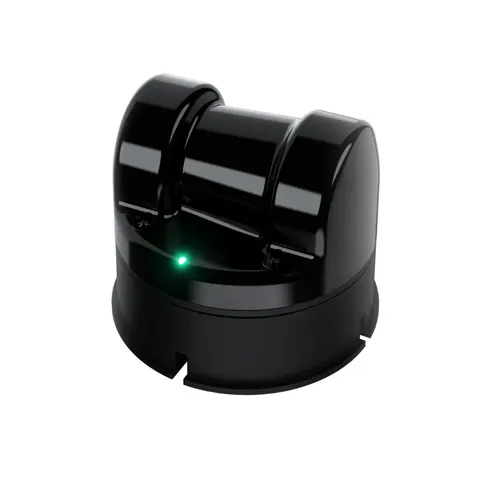
Panoramic LiDAR for mobile-robot mapping: 40 m at 10% reflectivity under 100 klx, 200,000 first-return points/s and a built-in IMU. Budget for the documented startup load as well as the 6.5 W normal operating power.
Choosing this model
Read the product documentationSourcebotics selection notes, based on the published documentation.
Application fit
- Panoramic perception on AMRs and compact mobile platforms.
- LiDAR–IMU mapping where sensor mass and power matter.
Integration planning
- The manual places the 40 m / 10% range near the lower vertical field boundary; range decreases toward the upper boundary.
- Use a metal mounting plate at least 3 mm thick with at least 10,000 mm² exposed for cooling and 10 mm surrounding clearance.
- The manual gives startup reference values, not a guaranteed maximum for every unit. Confirm the supply transient and cable voltage drop.
Selection considerations
- Confirm the exact model, firmware, cable, power supply and host software in the quotation.
- Manufacturer documentation establishes reference conditions; it does not replace application testing or confirm current availability.
Technical specifications
Product documentation| Range at 100 klx | 40 m at 10% reflectivity; 70 m at 80%Reference ↗ |
| Field of view | 360° horizontal; −7° to +52° verticalReference ↗ |
| Point rate | 200,000 points/s, first returnReference ↗ |
| Range precision | ≤2 cm (1σ), 10 m, 80% reflectivity, 25°CReference ↗ |
| Close-range reference zone | 0.1–0.2 m; precision not guaranteedReference ↗ |
| Near-field precision | ≤3 cm (1σ) at 0.2 m, 80% reflectivity, 25°C; small/dark targets at 0.1–1 m not guaranteedReference ↗ |
| Interface / synchronization | 100BASE-TX; PTPv2 or GPSReference ↗ |
| Built-in IMU | ICM40609Reference ↗ |
| Mass / dimensions | 265 g; 65 × 65 × 60 mmReference ↗ |
| Power supply | 9–27 V DC; 6.5 W averageReference ↗ |
| Operating temperature / enclosure | −20 to +55°C; IP67Reference ↗ |
| Power budget | 6.5 W normal; manual: 18 W startup below 35°C (~8 s), 9 W above 35°C (~8 s); up to 14 W self-heating at −20 to 0°CReference ↗ |
| SDK / driver generation | Livox SDK2; MID-360 added in SDK2 1.0.0 and livox_ros_driver2 1.0.0. Pin compatible SDK, driver, firmware and ROS distribution.Reference ↗ |
| Firmware reference | V13.18.0244; release notes dated April 11, 2025Reference ↗ |
Reference specifications for the listed model. Options, test conditions and integration requirements should be confirmed for your selected configuration.
Supplier
Livox develops LiDAR for mobile robotics, mapping and autonomous systems. Its website dates the brand to 2016. Select the exact MID-360, MID-360S or Avia variant and confirm its SDK, firmware, contracting entity and destination-specific service terms.
Downloads
Product documentation
Manufacturer and distributor references for model selection and technical review. Latest reference check: September 22, 2026.
- livoxtech.com · reference 1
- terra-1-g.djicdn.com · reference 2
- livoxtech.com · reference 3
- terra-1-g.djicdn.com · reference 4
- livoxtech.com · reference 5
- raw.githubusercontent.com · reference 6
- raw.githubusercontent.com · reference 7
- raw.githubusercontent.com · reference 8
- raw.githubusercontent.com · reference 9
- terra-1-g.djicdn.com · reference 10
Configuration & quotation
Specify the exact model or variant, required interfaces and accessories, quantity and delivery destination. Use the quotation to confirm the supplied configuration, current availability and commercial terms.
Ask for the current datasheet, delivery schedule, warranty scope and any documentation required for your destination. Use our procurement checklist to prepare the requirements, or download the worksheet.
Discuss this configurationFAQ
Is 14 W the maximum startup requirement?
No. The 14 W figure is cold self-heating. Manual v1.2 also gives an approximately eight-second startup of 18 W below 35°C, or 9 W above 35°C. The values are references and vary by unit.
Does 40 m apply across the whole field of view?
The manual associates the 10%-reflectivity 40 m return with the lower vertical field boundary; reach decreases toward the upper edge. Returns at 0.1–0.2 m are reference-only. Test the installed coverage.
Related models
Considering Livox Mid-360 Hemispherical LiDAR? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk