
APPLICATION
Mobile Manipulation: Bases, Arms and Sensing
Short answer
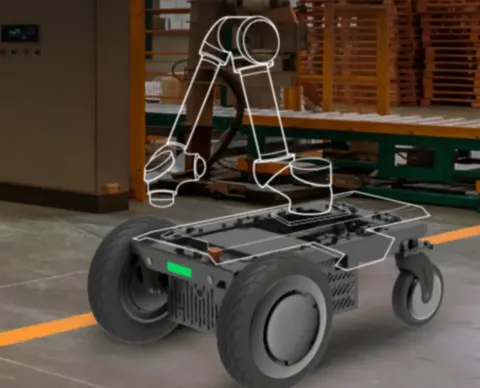
A mobile manipulator combines an open mobile base with a lightweight arm, a gripper or hand, and sensors for navigation and grasping. The hard parts are power, mounting and software: check that the base can power and carry the arm, and that both expose interfaces your navigation and motion stack can use together.
Mobile manipulation moves the arm to the work instead of bringing the work to the arm. Most projects combine an open AMR or chassis with a collaborative or lightweight arm, so the integration between the two decides how quickly the robot becomes useful.
Components you need
| Component | Role in the system | Parameters to specify |
|---|---|---|
| Mobile Robots (AMR/AGV) | Open mobile base |
|
| Research Robotic Arms | Manipulator |
|
| Hands & Grippers | Gripper or hand |
|
| LiDAR | Navigation and obstacle detection |
|
| 3D Vision | Grasp perception |
|
Model combinations to shortlist
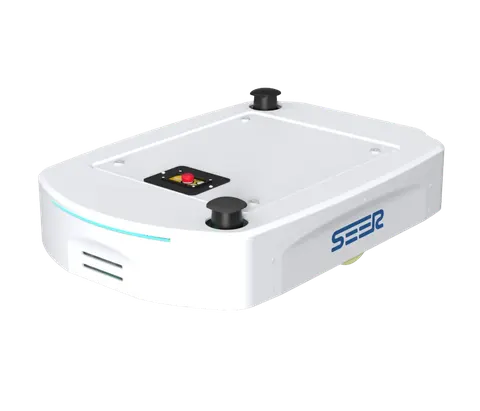
Open mobile bases
Chassis and AMR platforms offered for integration.
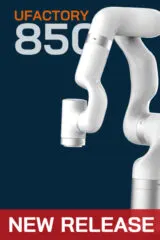
Lightweight arms
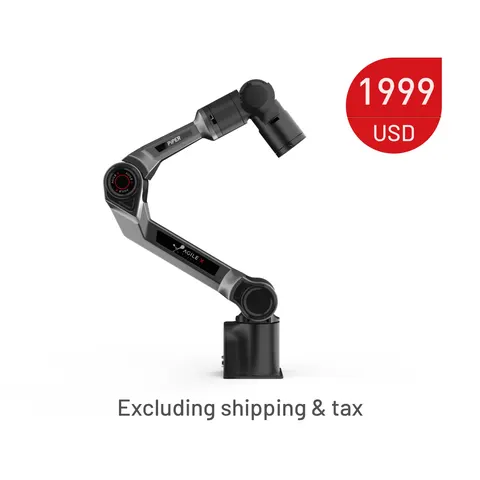
Arms often mounted on mobile bases; compare mass and supply voltage.
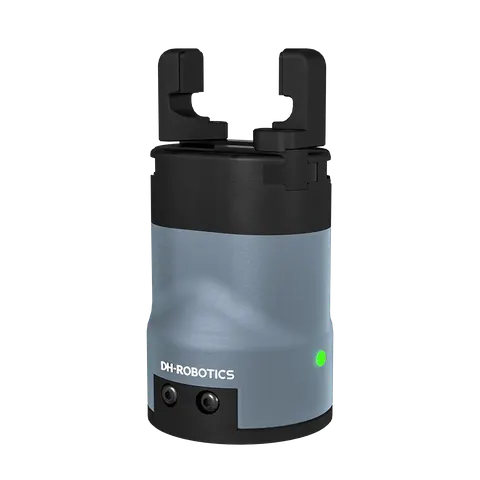
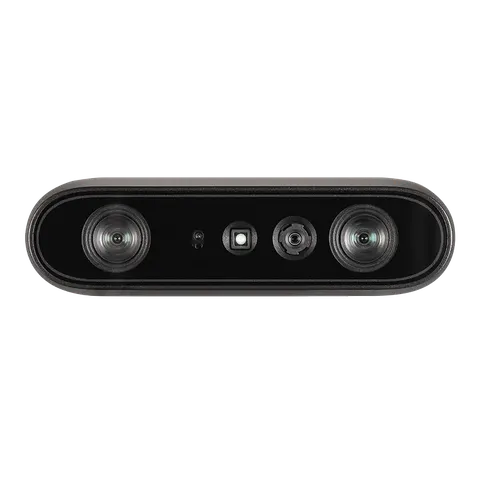
Grippers and sensing
End effectors and sensors for grasping and navigation.
- Technology
- Active and passive stereo IR
- Depth Range
- 0.10-20 m+ (optimal 0.26-3 m)
- Depth Accuracy
- <1.5% @2 m
- Range at 100 klx
- 40 m at 10% reflectivity; 70 m at 80%
- Field of view
- 360° horizontal; −7° to +52° vertical
- Point rate
- 200,000 points/s, first return
Common integration issues
- Power budget
- The arm, gripper, sensors and compute all draw from the base battery. Add up peak and average power and confirm the base's auxiliary output and runtime with that load.
- Stability
- An extended arm shifts the centre of mass. Check the base's allowed payload position and limit arm motion while driving.
- Two software stacks
- Navigation and arm control usually come from different suppliers. Confirm both offer ROS 2 or documented APIs you can coordinate.
Related guides
FAQ
Can any arm be mounted on any base?
Only if mass, power, mounting and communication match. Send both model names in your inquiry so compatibility can be confirmed.
Do I need a 3D camera as well as LiDAR?
LiDAR handles navigation; a depth camera near the gripper is usually needed to locate objects for grasping.
Planning a robotics purchase? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk