
APPLICATION
Legged Robots: Platforms and Components
Short answer
Buy a complete quadruped if you need a working legged platform quickly; build with quasi-direct-drive joint modules if locomotion hardware is your research. In both cases, check torque under thermal load, impact tolerance, the control interface and the sensors used for terrain perception and state estimation.
Legged robots load their joints with repeated impacts and rapid torque changes. That favours back-drivable joints, robust state estimation and a control stack that can run at a high, steady rate. Complete platforms package these choices; custom builds let you change them.
Components you need
| Component | Role in the system | Parameters to specify |
|---|---|---|
| Quadrupeds | Complete legged platform |
|
| Actuators & Joint Modules | Leg joints for custom robots |
|
| LiDAR | Terrain mapping and localization |
|
| IMU & Positioning | Body state estimation |
|
Model combinations to shortlist
Complete quadrupeds
Research and industrial quadrupeds; compare editions and SDK access on each model page.
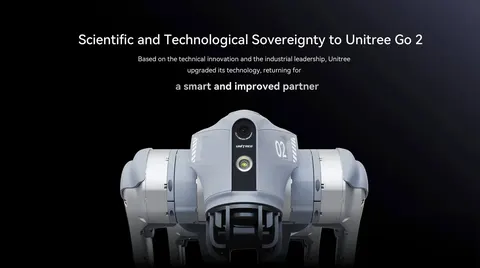
- Weight (with battery)
- About 15 kg
- Nominal payload
- About 8 kg
- Development access
- Secondary development supported on EDU; confirm low-level access and software version in the quotation
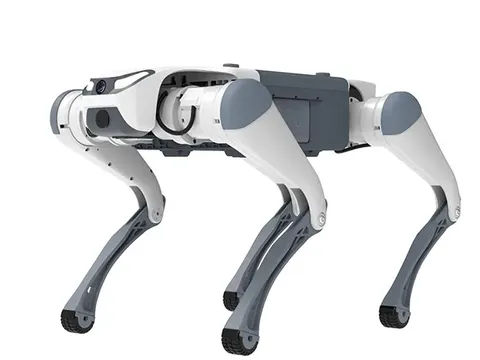
- Dimensions
- 610 x 370 x 406-496 mm (standing)
- Weight
- 12-13.5 kg (with battery)
- DoF
- 12
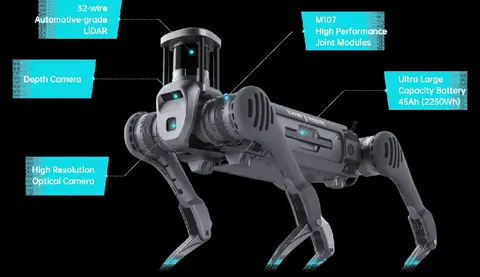
- Weight (with battery)
- About 60 kg
- Ingress protection
- IP67
- Walking load
- Over 40 kg
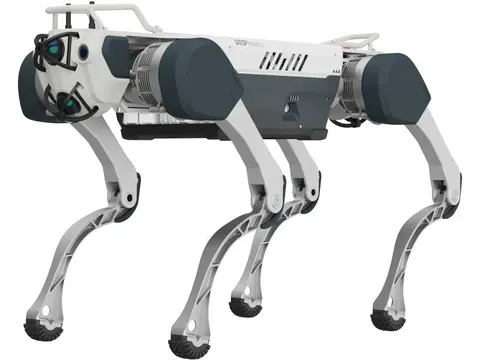
- Weight
- 56 kg
- Standing dimensions
- 1,000 × 695 × 470 mm
- Maximum speed
- ≥4 m/s, manufacturer test conditions
Joints for custom legs
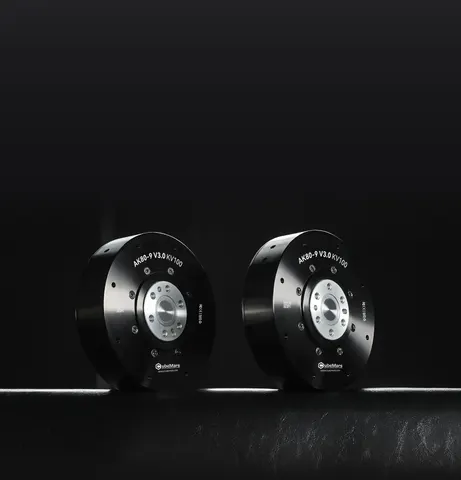
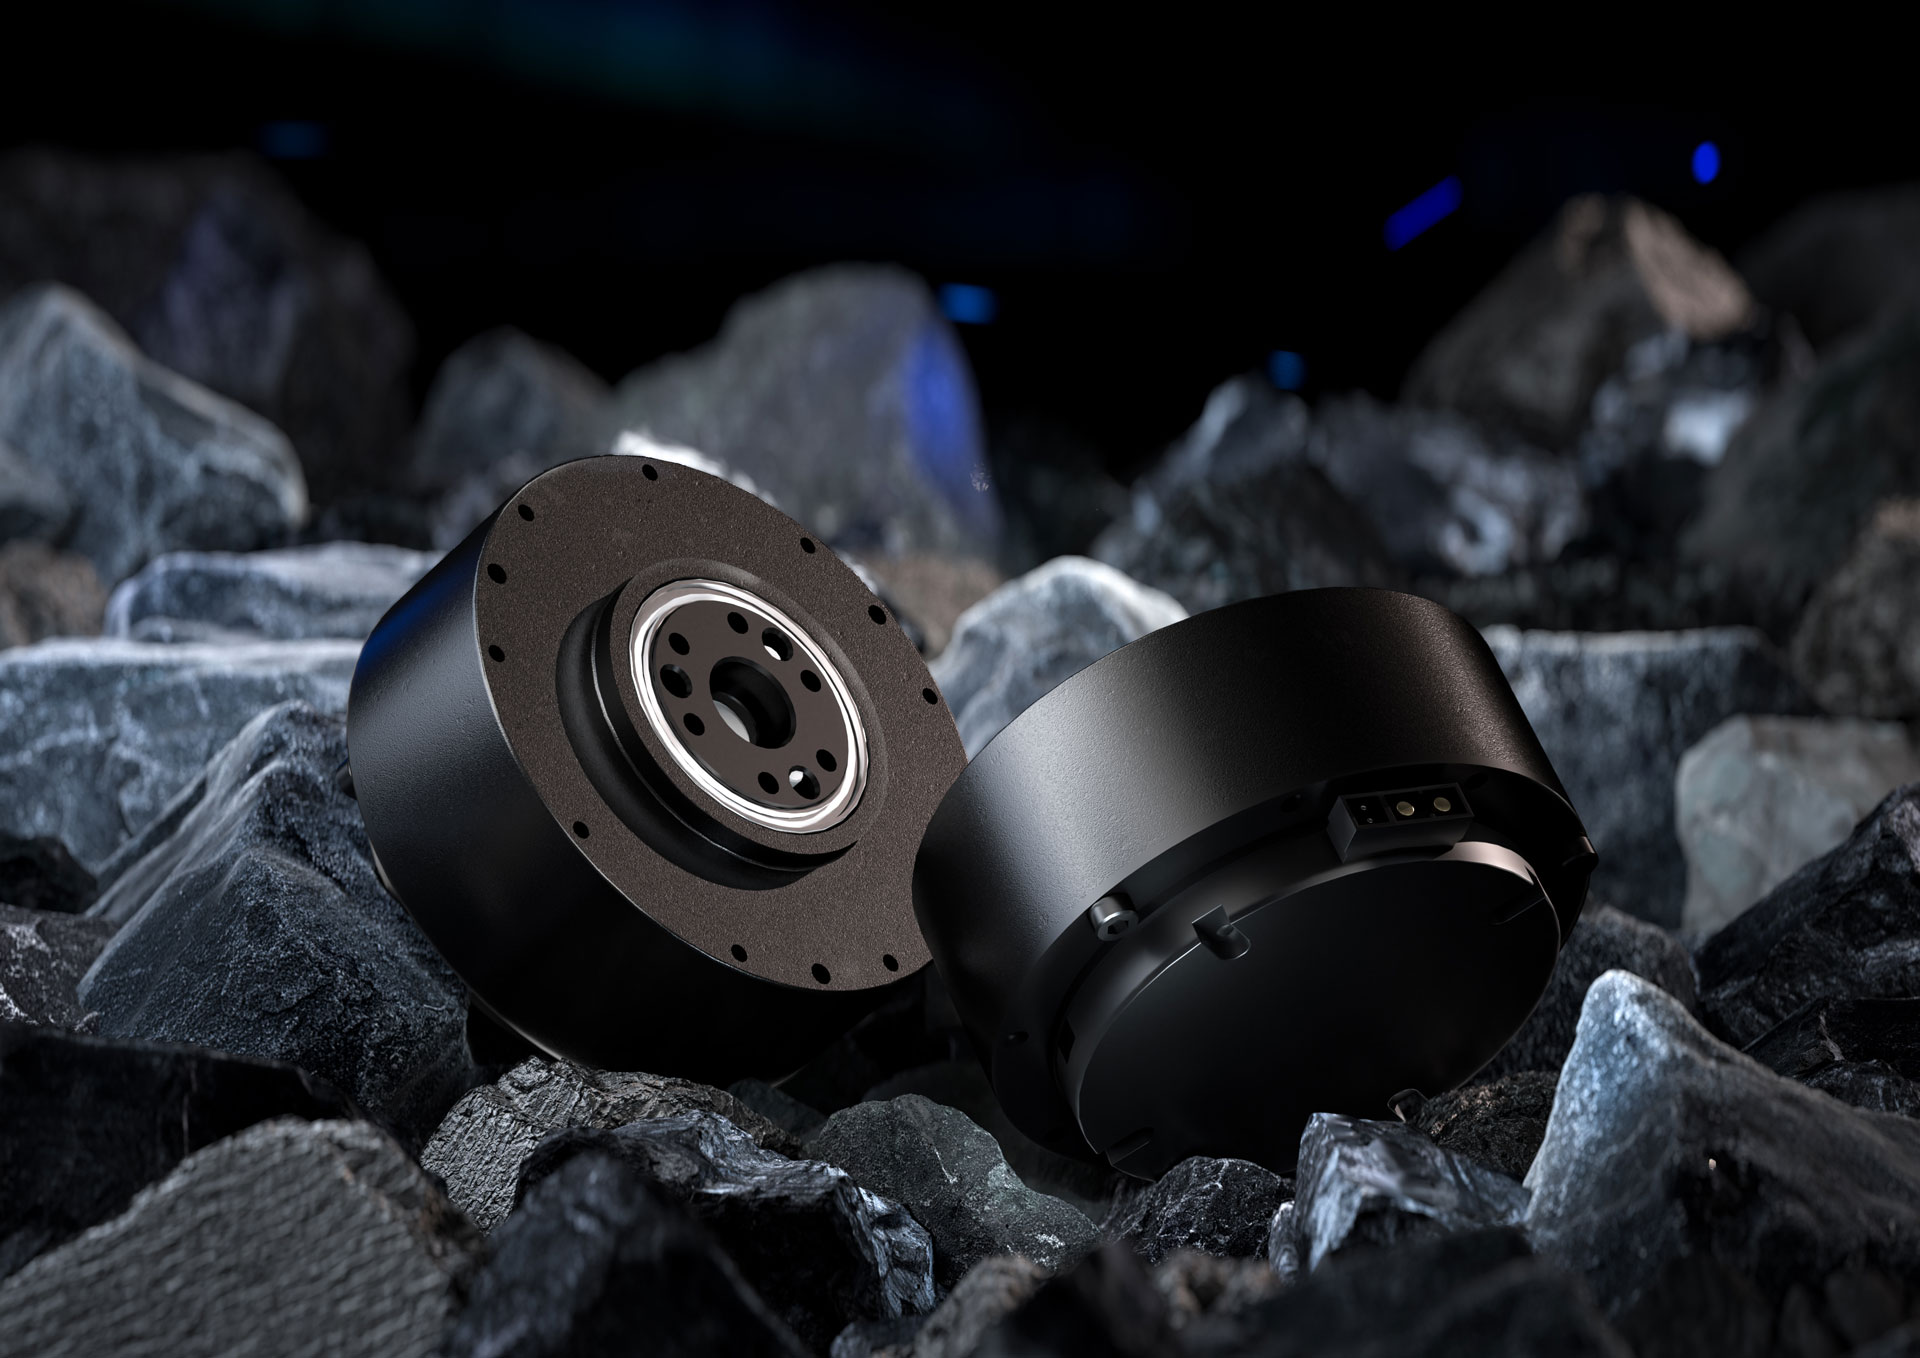
Planetary joint modules with document-matched torque and interface data.
- Peak Torque
- 17 N·m; short-duration load
- Nominal supply
- 36 VDC
- Encoder arrangement
- 1 magnetic encoder; 14-bit single-turn absolute resolution
- Rated Torque
- 10 N·m
- Peak Torque
- 20 N·m
- Reduction ratio
- 6:1
- Rated Torque
- 3.5 N·m
- Peak Torque
- 12.5 N·m
- Rated speed
- 120 rpm
Perception and state estimation
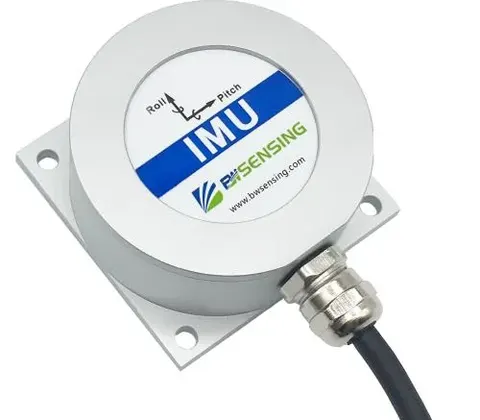
Sensors commonly mounted on legged platforms.
- Range at 100 klx
- 40 m at 10% reflectivity; 70 m at 80%
- Field of view
- 360° horizontal; −7° to +52° vertical
- Point rate
- 200,000 points/s, first return
Common integration issues
- Thermal limits in the leg
- Joint ratings assume a stated mounting plate and ambient temperature. Enclosed legs run hotter, so test rated torque in your housing before finalizing the design.
- Impact loads
- Landings and falls load gear teeth and bearings. Ask suppliers for impact or momentary torque limits, and plan spare joints.
- Control loop rate
- Locomotion controllers need consistent update rates across all joints. Check bus loading with the number of joints you will chain on each bus.
Related guides
FAQ
Can I run my own locomotion controller on a commercial quadruped?
Only on editions that expose low-level joint control. Confirm the edition and SDK capabilities in the quotation.
Which joint type suits a custom leg?
Low-ratio planetary, quasi-direct-drive joints are the usual choice because they tolerate impacts and allow force estimation from motor current.
Planning a robotics purchase? Share the quantity, configuration and destination so we can check fit, availability and quote requirements.
Request a quote— The Sourcebotics sourcing desk