Electric Robot Grippers from China
Compare electric grippers for repeatable pick-and-place and contact tasks. Match the opening and stroke to your part, then compare gripping-force conditions, finger tooling, wrist mounting and controller connection.
Choose a manufacturer, then narrow the requirements for this product type.
MANUFACTURER
TOTAL DOF
Any
ACTIVE DOF
Any
FINGERS
STROKE (MM)
Any
PRICE BAND
TACTILE SENSING
INTERFACE
Showing 39 of 39 models
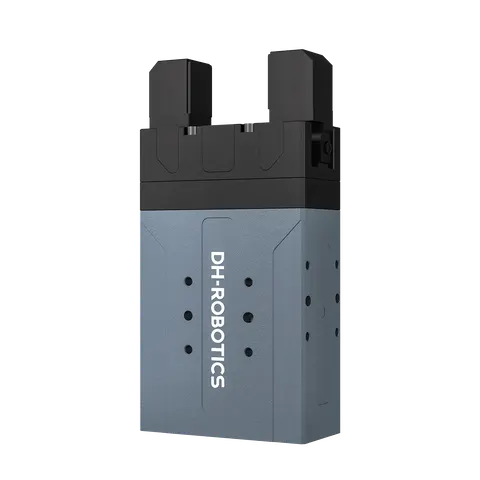
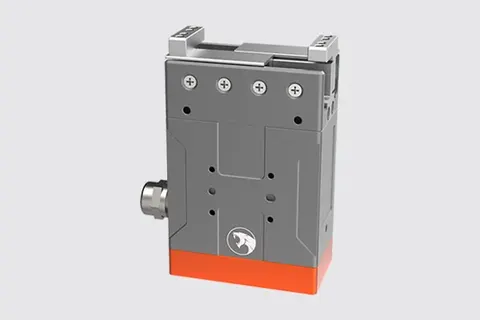
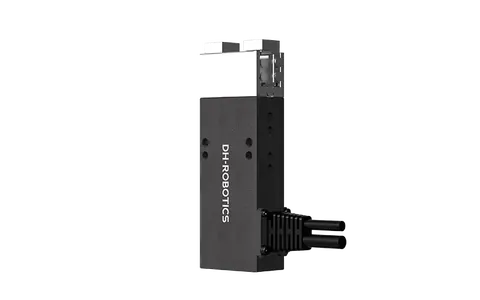
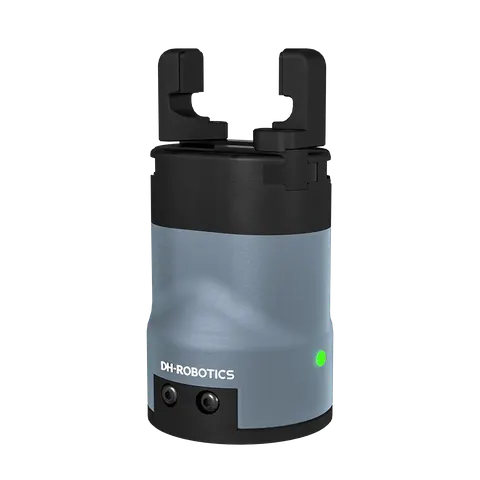
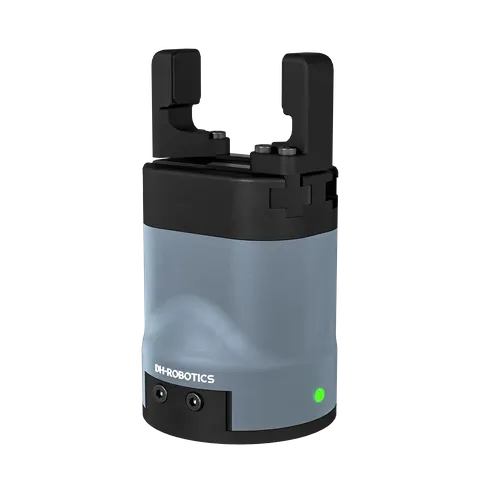
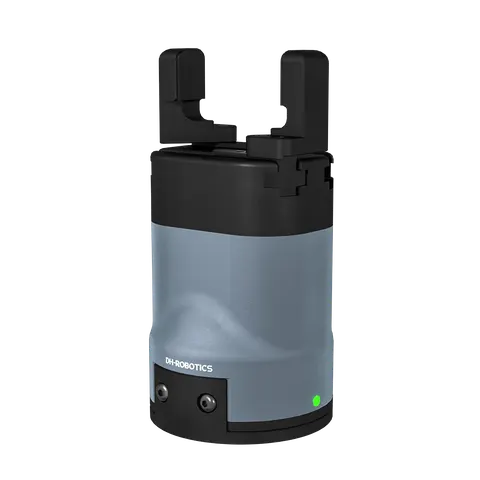
DH-Robotics AG-160-95
- Gripper type
- Two-finger adaptive linkage
- Grip force (per jaw)
- 45–160 N
- Total stroke
- 95 mm
Price on request
DH-Robotics AG-105-145
- Gripper type
- Two-finger adaptive linkage
- Grip force (per jaw)
- 35–105 N
- Total stroke
- 145 mm
Price on request
DH-Robotics DH-3
- Fingers
- 3
- Grip Force
- 10-65 N per jaw
- Stroke
- 106 mm parallel / 122 mm centric
Price on request
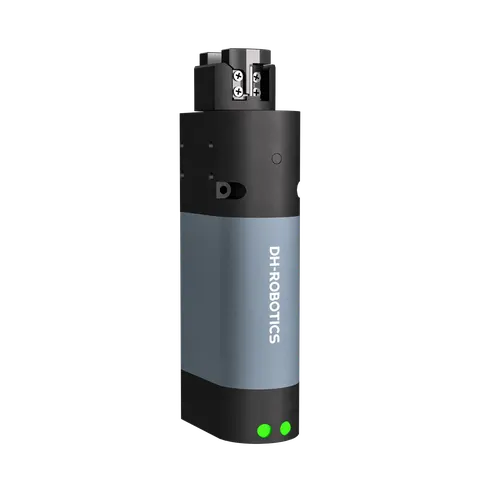
DH-Robotics RGIC-35-12
- Gripper type
- Two-jaw grip-and-rotate
- Grip force (per jaw)
- 13–35 N
- Total stroke
- 12 mm
Price on request
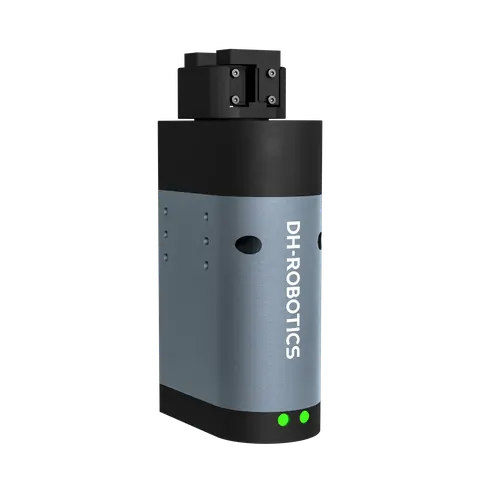
DH-Robotics RGI-100-14
- Gripper type
- Two-jaw grip-and-rotate
- Grip force (per jaw)
- 30–100 N
- Total stroke
- 14 mm
Price on request
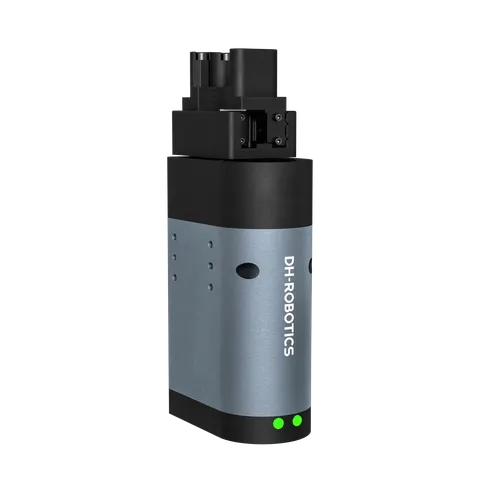
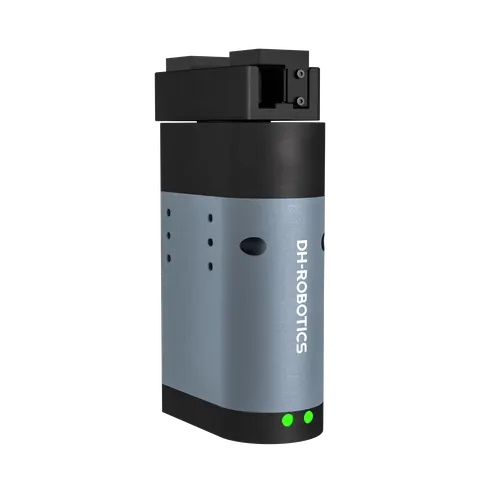
DH-Robotics RGI-100-30
- Gripper type
- Two-jaw grip-and-rotate
- Grip force (per jaw)
- 30–100 N
- Total stroke
- 30 mm
Price on request
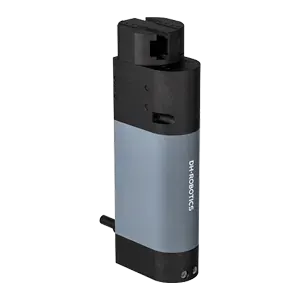
DH-Robotics RGIC-100-35
- Gripper type
- Two-jaw grip-and-rotate
- Grip force (per jaw)
- 40–100 N
- Total stroke
- 35 mm
Price on request
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quoteCompare 39 matching models
| Model | Fingers | Grip force / conditions | Stroke | Interface | Quote | |
|---|---|---|---|---|---|---|
| Daimon Robotics DM-Tac G | 2 | Request specification | 95 mm | 1000 | RS-485 | Quote |
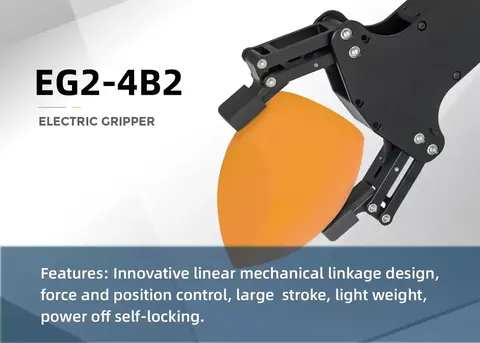
| Inspire Robots EG2-4B2 | 2 | 0-15 N | 70 mm | 223 | RS-485 | Quote |
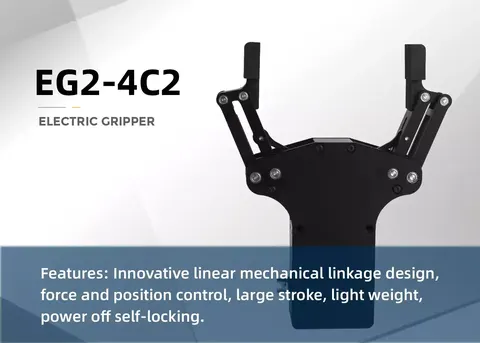
| Inspire Robots EG2-4C2 | 2 | 0-20 N | 70 mm | 231 | RS-485 | Quote |
| DH-Robotics PGE-5-26 | 2 | 0.8-5 N per jaw | 26 mm | 400 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGE-8-14 | 2 | 2-8 N per jaw | 14 mm | 400 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-R | 2 | 30-80 N | 20 mm | 500 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-20S | 2 | 8-20 N | 20 mm | 350 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-20F | 2 | 1-8 N | 20 mm | 500 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-26 | 2 | 6-15 N | 26 mm | 450 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-30 | 2 | 10-40 N | 30 mm | 550 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-50 | 2 | 15-50 N | 50 mm | 700 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-100 | 2 | 35-60 N | 90 mm | 925 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-ERG-20 | 2 | 10-35 N | Request specification | 1000 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-2-10 | 2 | 0.8-2 N per jaw | 10 mm | 150 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-15-10 | 2 | 6-15 N per jaw | 10 mm | 150 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-15-26 | 2 | 6-15 N per jaw | 26 mm | 500 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-50-26 | 2 | 15-50 N per jaw | 26 mm | 500 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-100-26 | 2 | 30-100 N per jaw | 26 mm | 600 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-15-40 | 2 | 6-15 N per jaw | 40 mm | 600 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-50-40 | 2 | 15-50 N per jaw | 40 mm | 600 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGEA-100-40 | 2 | 30-100 N per jaw | 40 mm | 600 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGC-50-35 | 2 | 15-50 N per jaw | 37 mm | 500 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGC-140-50 | 2 | 40-140 N per jaw | 50 mm | 1000 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGC-300-60 | 2 | 80-300 N per jaw | 60 mm | 1500 | Modbus RTU / RS-485 | Quote |
| DH-Robotics PGI-140-80 | 2 | 40-140 N per jaw | 80 mm | 1000 | Modbus RTU / RS-485 | Quote |
| DH-Robotics AG-160-95 | 2 | 45–160 N per jaw | 95 mm total | 1000 | Modbus RTU / RS-485 | Quote |
| DH-Robotics AG-105-145 | 2 | 35–105 N per jaw | 145 mm total | 1300 | Modbus RTU / RS-485 | Quote |
| DH-Robotics DH-3 | 3 | 10-65 N per jaw | 106 mm parallel / 122 mm centric | 1680 | TCP/IP | Quote |
| DH-Robotics RGIC-35-12 | 2 | 13–35 N per jaw | 12 mm total | 640 | Modbus RTU / RS-485 | Quote |
| DH-Robotics RGI-100-14 | 2 | 30–100 N per jaw | 14 mm total | 1280 | Modbus RTU / RS-485 | Quote |
| DH-Robotics RGI-100-22 | 2 | 30-100 N per jaw | 22 mm | 1400 | Modbus RTU / RS-485 | Quote |
| DH-Robotics RGI-100-30 | 2 | 30–100 N per jaw | 30 mm total | 1500 | Modbus RTU / RS-485 | Quote |
| DH-Robotics RGIC-100-35 | 2 | 40–100 N per jaw | 35 mm total | 650 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EMG-4 | 2 | 3-5 N | 4 mm | 230 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-8S | 2 | 8-20 N | 8 mm | 250 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-FS | 2 | 8-20 N | 8 mm | 300 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-12 | 2 | 30 N | 12 mm | 342 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-L | 2 | 30 N | 12 mm | 400 | Modbus RTU / RS-485 | Quote |
| HITBOT Z-EFG-20 | 2 | 30-80 N | 20 mm | 458 | Modbus RTU / RS-485 | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
Plan the installed gripper
- Robot controller
- Control connection
- Power & cables
- Gripper & fingers
- Wrist adapter
Keep finger tooling and the adapter with the gripper in the load and opening calculation. List any external controller separately from the gripper body.
Request an itemized package →Electric Grippers FAQ
How do I choose stroke and opening for a part?
Start with the largest and smallest part dimensions at the intended grasp faces. Include approach clearance and finger-tool geometry. A listed stroke is travel; it does not by itself establish the opening with your fitted fingers.
How should gripping force be compared?
Keep the manufacturer's force definition with the value: per jaw or total, finger length and contact location. Give the supplier the part mass, surface, acceleration and grasp direction so the proposed setting addresses the actual move.
What belongs in the installed gripper package?
Itemize the gripper, custom fingers or pads, wrist adapter, power cable, communication cable and any external controller. Name the robot controller and required protocol, and include the matching command example or integration file.
What should the sample pick-and-place trial measure?
Use representative parts and the planned finger tooling. Record grasp success, dropped or marked parts, cycle time and the recovery sequence. Include the target cycle rate and daily duty in the inquiry.