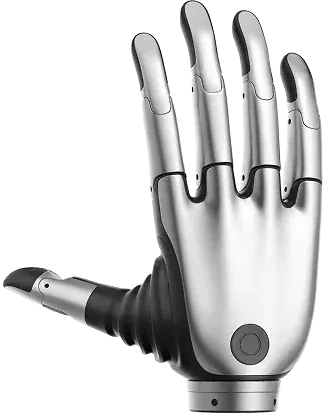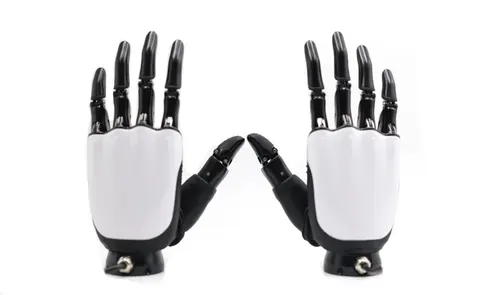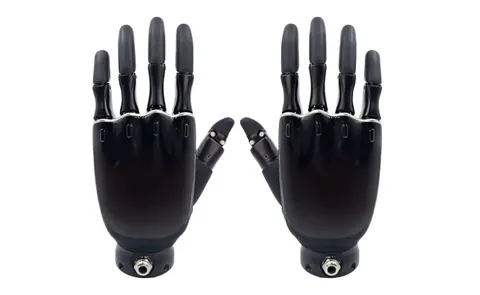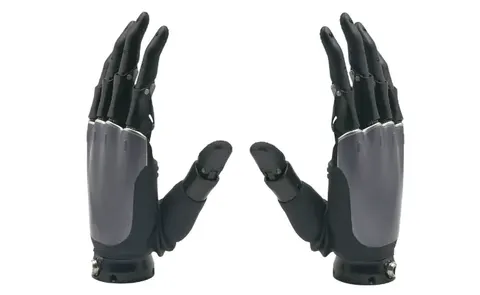
Inspire Robots RH56DFTP (tactile series)
- Controlled DOF
- 6
- Moving joints
- 12
- Fingertip repeatability
- ±0.2 mm
Price on request
Compare multi-finger hands for grasp learning, teleoperation and in-hand manipulation. Start with independent control axes, thumb motion and sensing, then size the wrist, power supply and host connection around the complete hand assembly.
Total DOF and active control axes are listed separately. Narrow by the requirements for your experiment.
No models match those filters. Tell us what you need—we source beyond the catalog.
Request a quote| Model | Fingers | Grip force / conditions | Tactile | Interface | Quote | |||||
|---|---|---|---|---|---|---|---|---|---|---|
| Inspire Robots RH56DFTP (tactile series) | 5 | Request specification | 12 | 6 | RH56DFTP: 5–17 tactile sensors by configuration | Request specification | Request specification | Ethernet | On request | Quote |
| Unitree Dex5-1 | 5 | Request specification | 20 | 16 | Base Dex5-1 has no pressure array; 12 arrays / 94 sensors belong to Dex5-1P | 10 | 1100 g | USB | On request | Quote |
| PaXini DexH13 GEN2 | 4 | Request specification | 13 | 13 | 1,140 ITPU GEN2 units; 3,420 tactile signal channels | 15 | Request specification | Request specification | On request | Quote |
| LinkerBot Linker Hand T20 | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | Request specification | On request | Quote |
| AgiBot OmniHand 2025 (without tactile) | Request specification | Request specification | 16 | 10 | No tactile sensor array in the standard model. | Request specification | ≤510 g, excluding wrist end cap and screws | CAN FD / RS-485 / USB | On request | Quote |
| Robot Era XHAND1 | 5 | Request specification | 12 | 12 | Optional tactile package; confirm on the order | 15 | 1100 g | Request specification | On request | Quote |
| BrainCo BrainCo × Tashan TS-F+ integration | Request specification | Request specification | Request specification | Request specification | TS-F+ sensing in the documented demonstration; delivered configuration to be specified | Request specification | Request specification | Request specification | On request | Quote |
| Stella Robot Pantheon Hand 22 (hand–forearm assembly) | 5 | Request specification | 22 | 17 | Manufacturer describes fingertip 3D force/tactile sensing | Request specification | 2260 g | CAN FD | On request | Quote |
| Unitree Dex3-1 | 3 | Request specification | 7 | 7 | Optional pressure-equipped configuration: 9 arrays with 33 sensing elements; confirm the quoted hand includes them. | Request specification | 710 g | USB | From $7,800 | Quote |
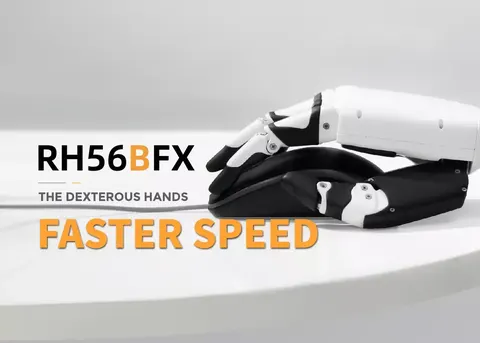
| Inspire Robots RH56BFX | 5 | 6 N thumb / 4 N fingers | 6 | 6 | Integrated force sensors | Request specification | 540 g | RS-485 | On request | Quote |
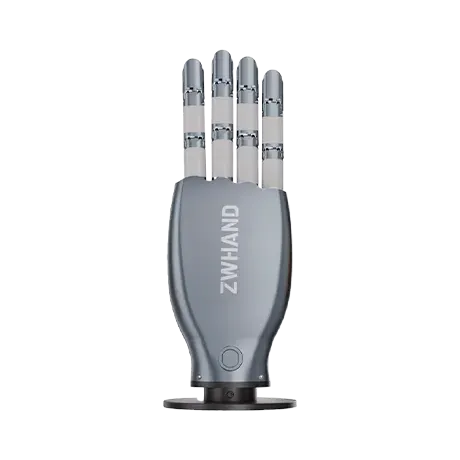
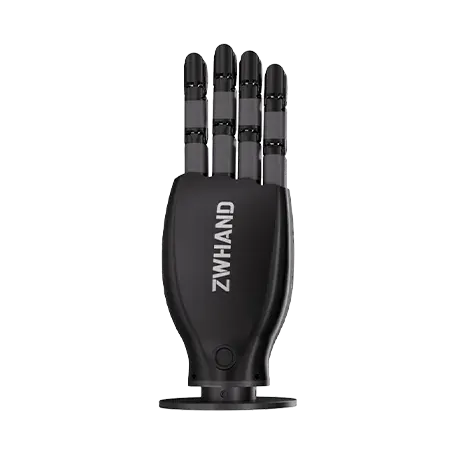
| ZWHAND DM17 | 5 | 5-12 N fingertip force (four fingers) | 17 | 17 | Flexible e-skin, 0.02 N/cm2 sensitivity, >=100 Hz sampling, >=1 million cycles | Request specification | Request specification | Request specification | On request | Quote |
| ZWHAND LM06 | 5 | 150 N single-hand | 16 | 6 | Flexible e-skin, 0.02 N/cm2 sensitivity, >=100 Hz sampling | Request specification | Request specification | Request specification | On request | Quote |
| BrainCo Revo2 BASIC | 5 | >=50 N fist, >=15 N pinch | 11 | 6 | Not fitted on BASIC | Request specification | 383 g (without wrist) | RS-485 / CAN FD | On request | Quote |
| BrainCo Revo2 PRO | 5 | >=50 N fist, >=15 N pinch | 11 | 6 | No | Request specification | 383 g | RS-485 / CAN FD / EtherCAT | On request | Quote |
| BrainCo Revo2 TOUCH | 5 | >=50 N fist, >=15 N pinch | 11 | 6 | Yes - integrated tactile sensing | Request specification | 383 g | RS-485 / CAN FD / EtherCAT | On request | Quote |
| OYMotion ROH-A002 | 5 | >=4.41 N per fingertip, >=9.8 N thumb | 11 joints | 6 | Request specification | Request specification | 545 +/-5 g | UART / RS-485 / CAN | On request | Quote |
| OYMotion ROH-AP001 | 5 | Request specification | Request specification | Request specification | 0.1-25 N sensing range | Request specification | 640 g | UART / RS-485 / CAN | On request | Quote |
| OYMotion ROH-AP002 | 5 | Request specification | 11 movable joints (independent total DoF not specified) | 6 | Finger force sensors and an 11 × 5 palm pressure matrix | Request specification | 626 ±5 g (including wrist) | Request specification | On request | Quote |
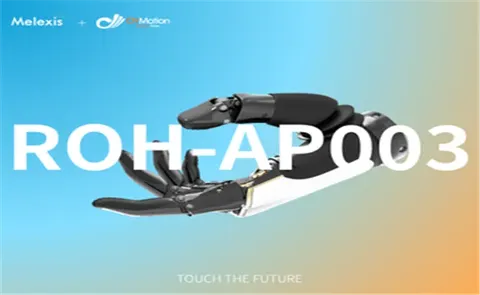
| OYMotion ROH-AP003 | 5 | Request specification | Request specification | Request specification | Melexis 3D tactile sensors | Request specification | Request specification | Request specification | On request | Quote |
Compare the listed configurations. Confirm required options, operating conditions and current pricing with your quotation.
Compare the same configuration and operating conditions. Reference prices exclude the final accessory and delivery package.
Name the left or right hand and sensing variant. Keep the adapter, cabling and hand mass together when checking the arm's tool-load allowance.
Request an itemized package →List the exact hand variant and left/right orientation, wrist adapter and fasteners, power supply and harness, host cable, control software and a spare-finger or service-parts option. Quote each hand separately when a left/right pair uses different accessories.
Use the same grasp task and object set. Compare the fitted sensing hardware, available signals, sample data and software interface for each quoted variant. The five-model hand comparison links the published configuration and documents for each model.
Send the arm model, wrist flange drawing, tool payload and centre-of-mass limits, supply voltage and host interface. Add the combined mass of the hand, adapter and cables to the tool-load calculation.
Specify the objects, dimensions, materials, grasp orientation and motion. Record successful grasps, slips, recovery time and any finger damage over the planned trials. Use that task record to compare candidates on the same basis.